HighTorque Robotics·HTPU-6035-04-CNE·RJT-070

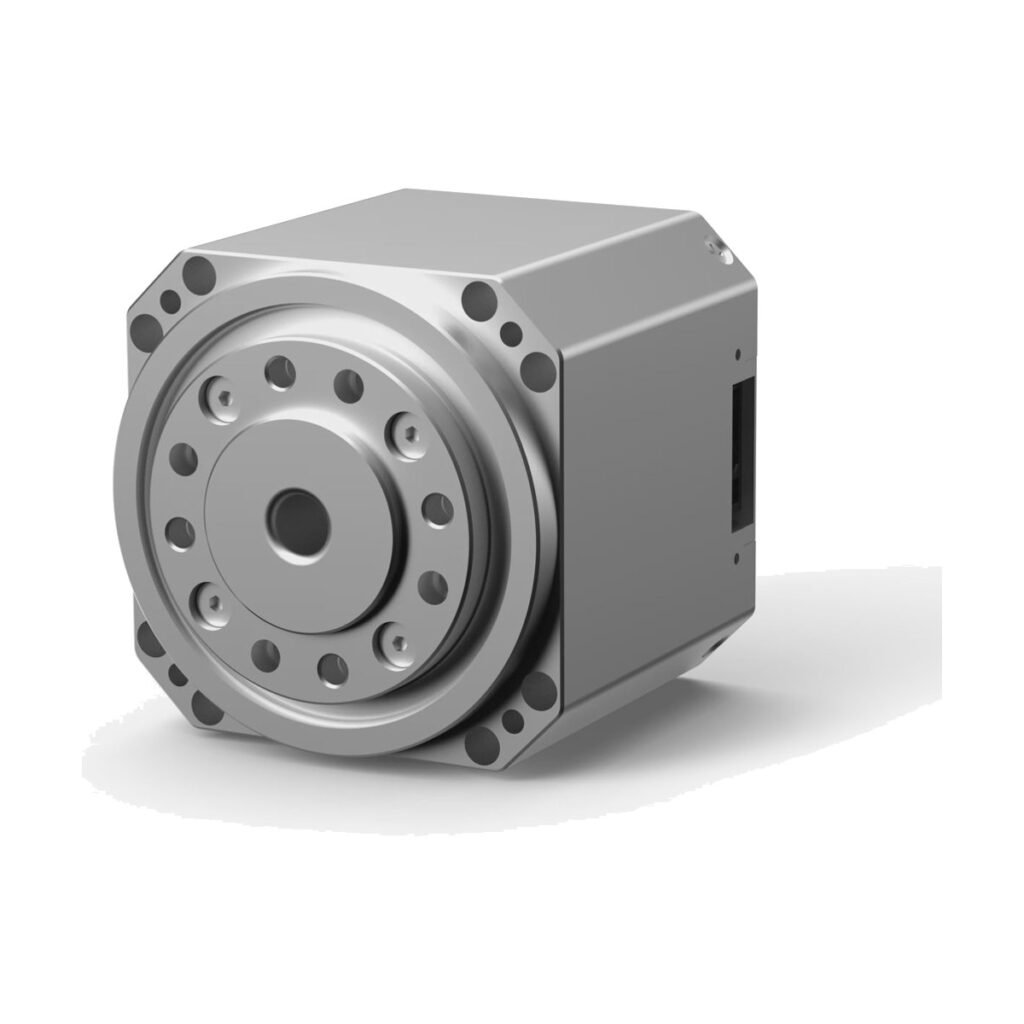
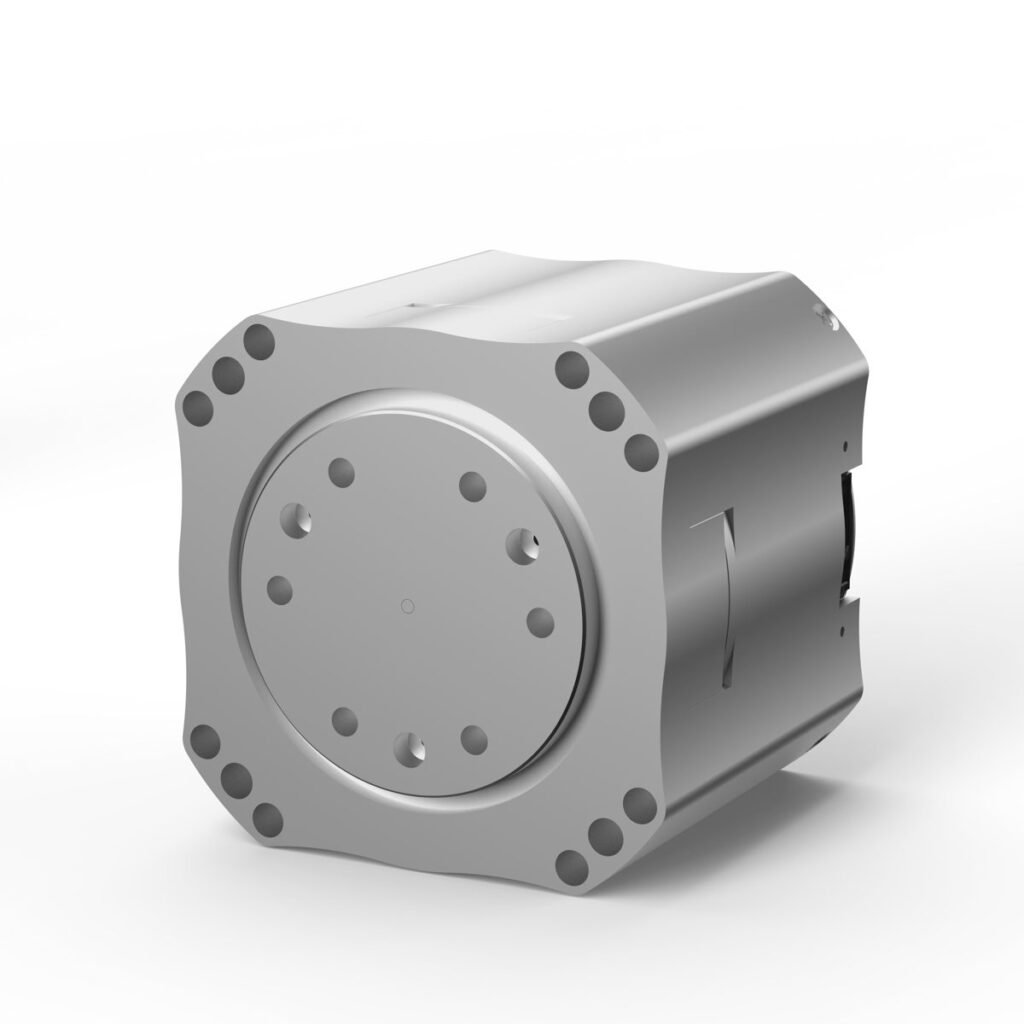
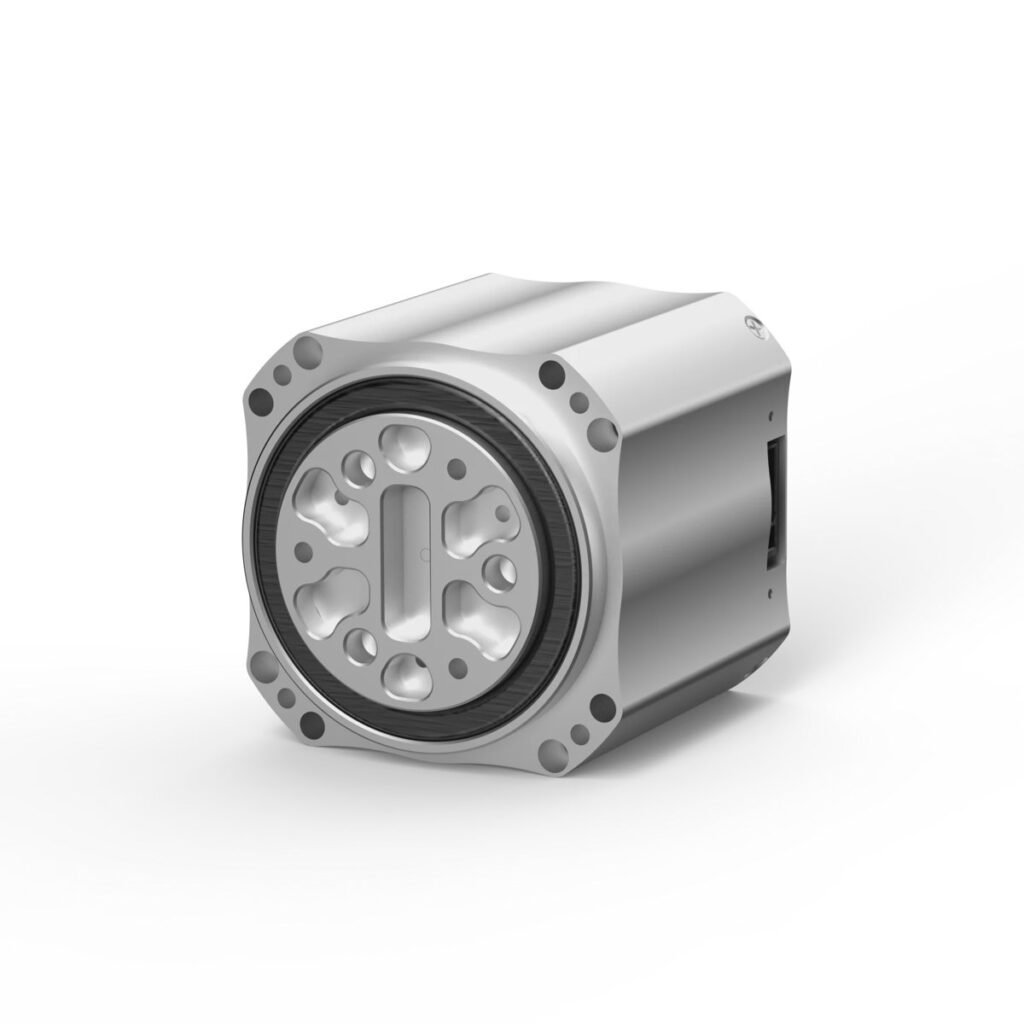
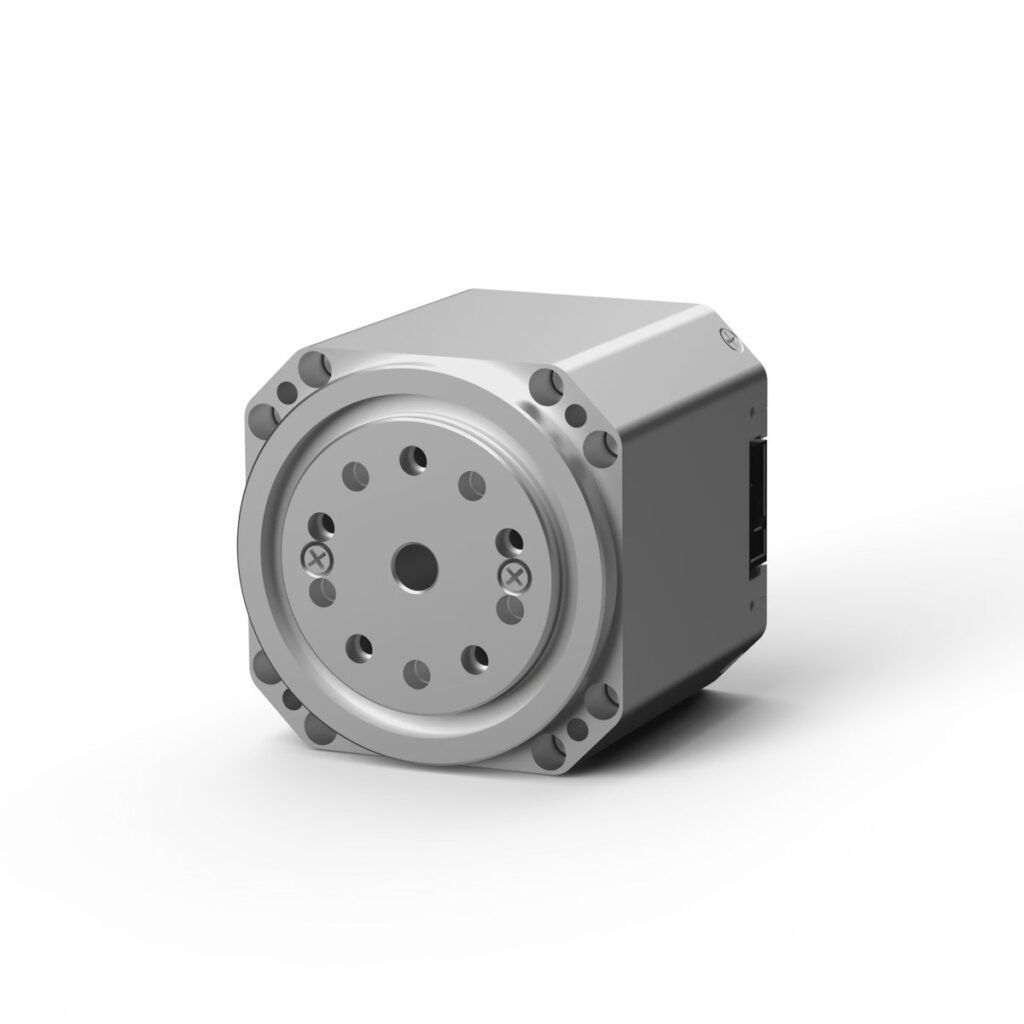
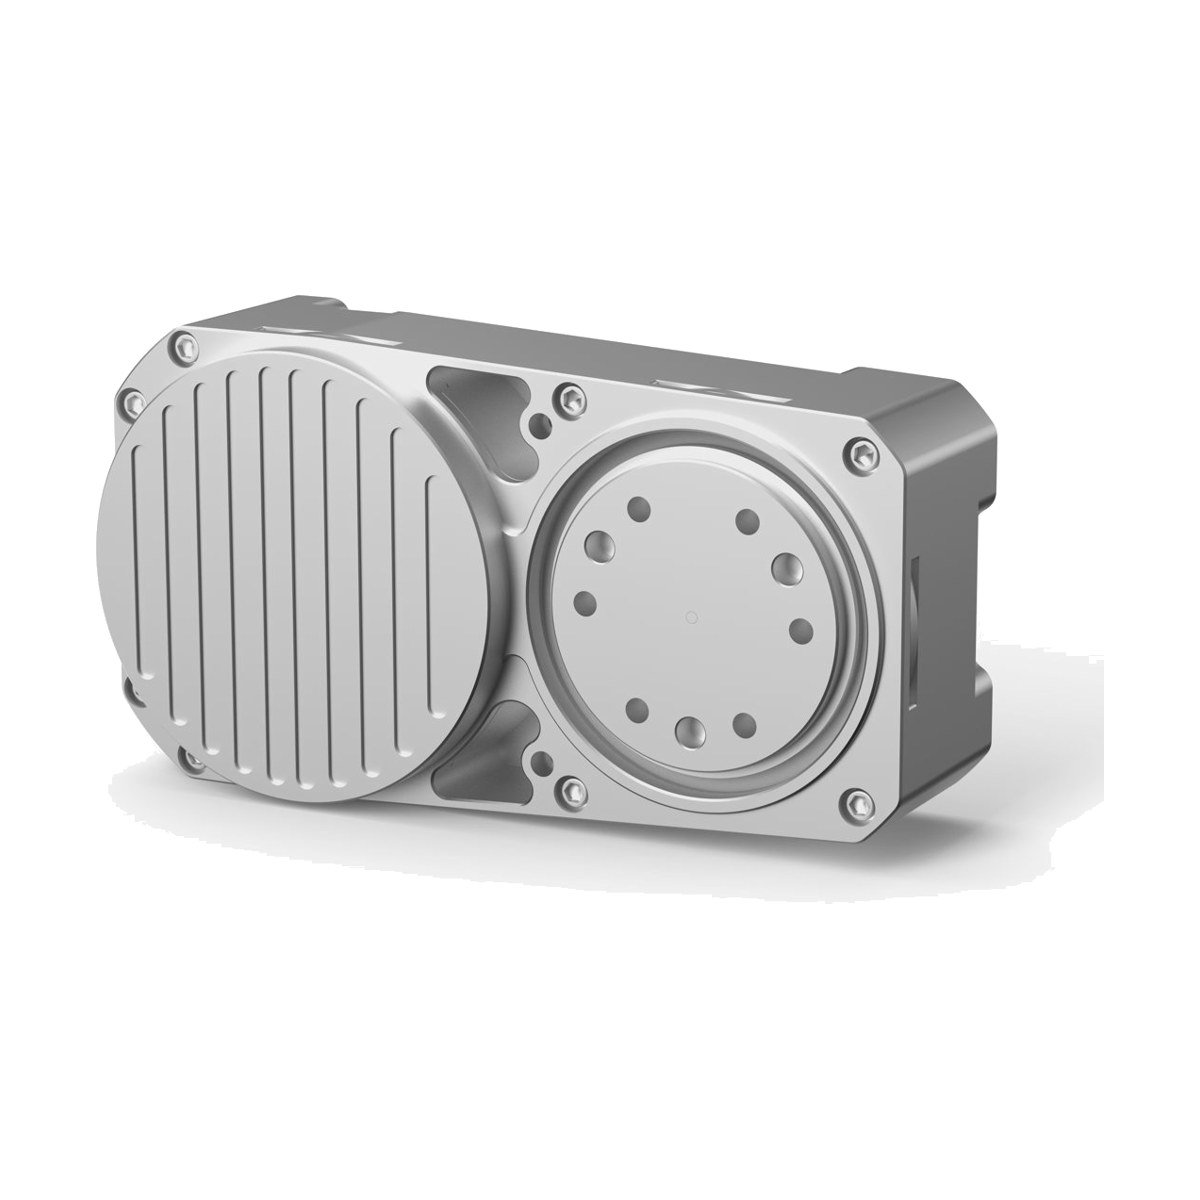
HighTorque HTPU-6035-04-CNE Joint Actuator

$306.90

The HTPU series joint modules are mainly composed of a reducer consisting of side-by-side gears and a planetary gear set, as well as a self-designed brushless DC motor.They feature low backlash torque, low torque ripple, and dual absolute encoders, supporting current or torque control.They are widely used in exoskeleton design, wearable devices, small humanoid robots,…

Freight
Quoted after order
Minimum order
1 unit
In the box
Motor, gearing and driver included
Need volume pricing or a custom configuration? Request a quote →
10 N·m
Torque (rated)
35:1
Gear ratio
CAN
Communication

Specifications

Performance

Torque (rated)
10 N·m
Output speed
50 rpm
Motion
Continuous rotary

Mechanical

Gear ratio
35:1
Weight
0.558 kg

Interface

Communication
CAN

Specifications and photos are the maker's published data. Datasheets are available on request.

Typical applications

  • Legged and humanoid robots
  • Robot arms and cobots
  • Exoskeletons
  • Research and education platforms

Choosing the right one

  • Use peak torque for dynamic moves and rated torque for sustained load; keep continuous load under the rated value.
  • Low ratios (about 6:1 to 10:1, quasi-direct drive) are backdrivable and suit legged robots; high ratios (30:1 and up) suit arms that need stiffness.
  • Check bus voltage (24 V or 48 V) and communication (CAN or CAN FD, EtherCAT, RS485) against your controller.
  • A dual encoder reports absolute output position at power-up, so the joint needs no homing.
  • Compare torque density (N·m per kg) when weight matters.

About this product

The HTPU series joint modules are mainly composed of a reducer consisting of side-by-side gears and a planetary gear set, as well as a self-designed brushless DC motor.They feature low backlash torque, low torque ripple, and dual absolute encoders, supporting current or torque control.They are widely used in exoskeleton design, wearable devices, small humanoid robots, robotic arms and other fields.Their unique flat design provides more options for transmission in various space-constrained scenarios.

  • Series: Joint module
  • Factory model: HTPU-6035-04-CNE
  • Made by HighTorque Robotics

More from HighTorque Robotics

Visit storefront →