Exoskeleton & wearable joints
Joint modules their makers design for exoskeletons and wearable assist devices: light, backdrivable and quiet.
- Backdrivability matters: the wearer must be able to move the joint when it is unpowered.
- Keep each joint light, since the wearer carries it.
-
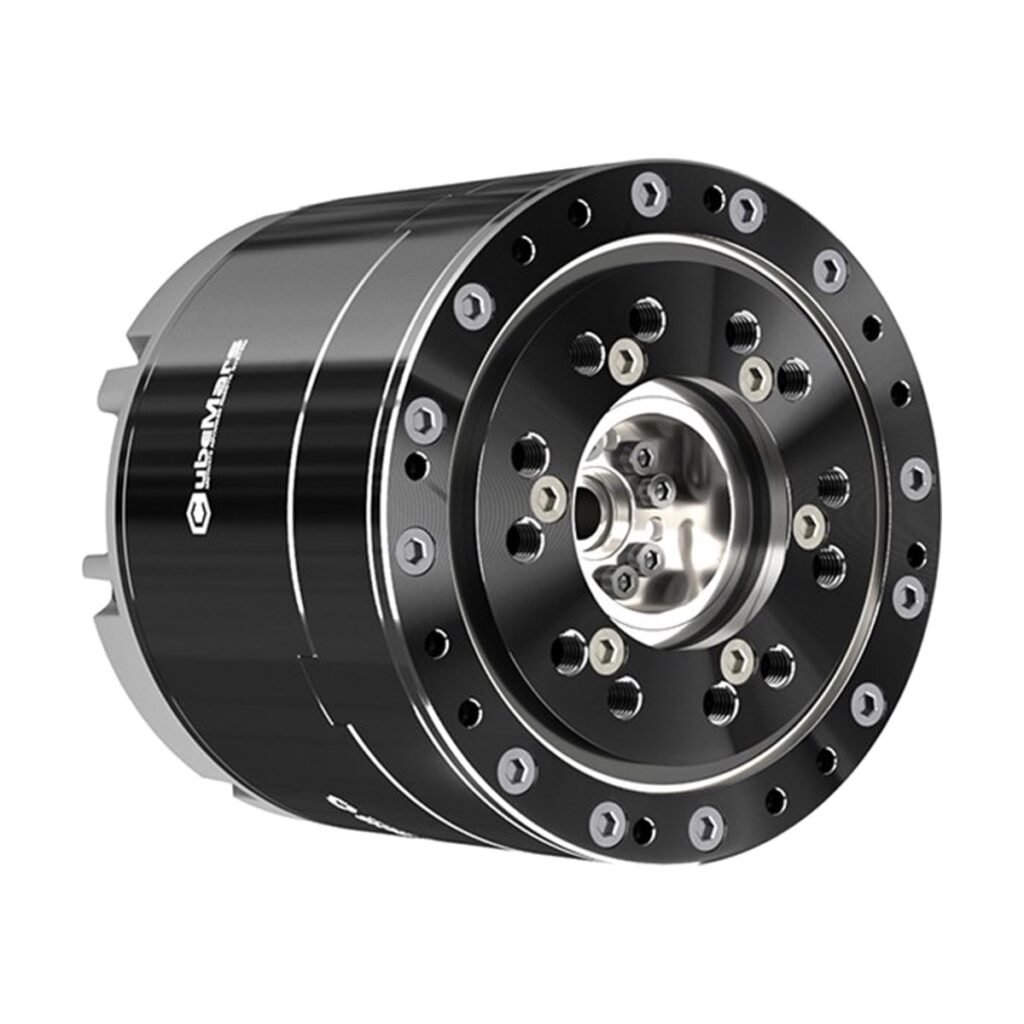
CubeMars AKH70-48 Hollow-Shaft Joint Actuator
222 N·m74 N·m48:1$768.90 -
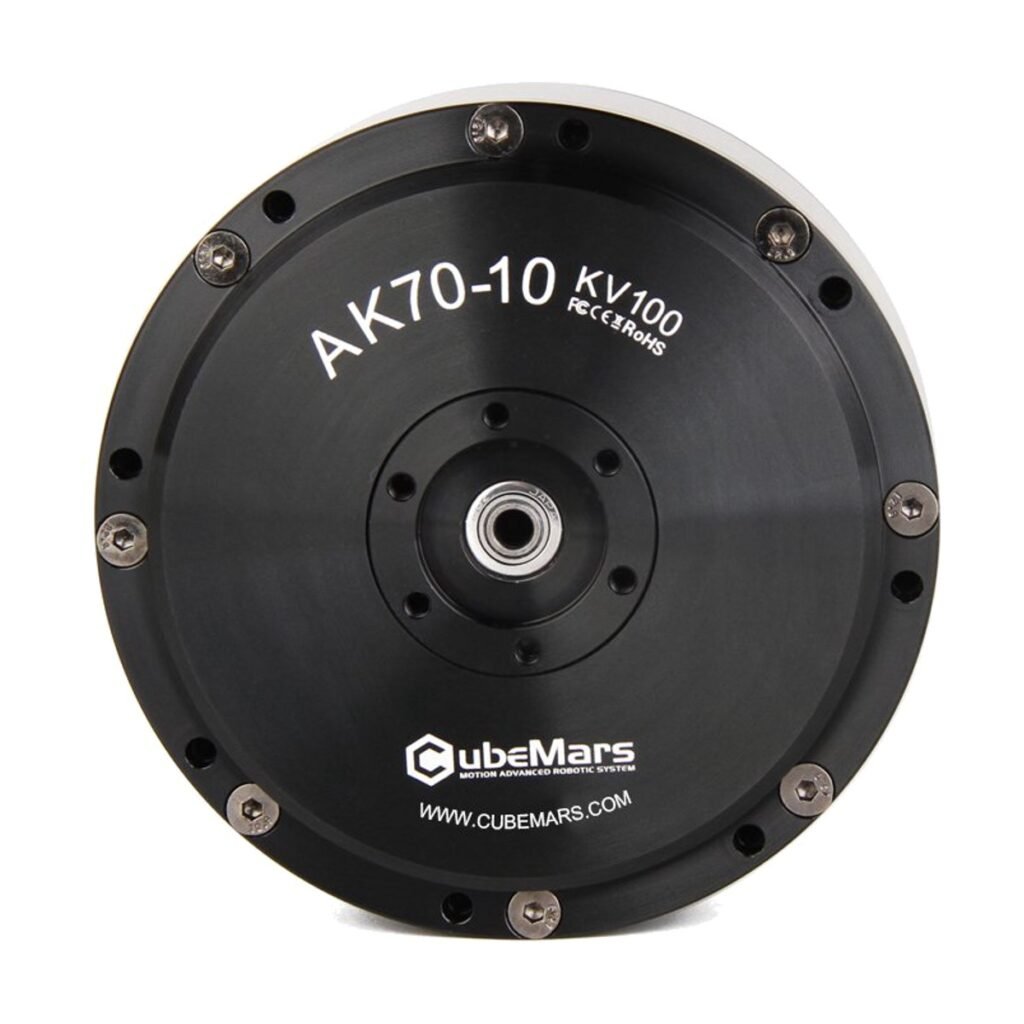
CubeMars AK70-10 Joint Actuator
24.8 N·m8.3 N·m10:1$438.90 -
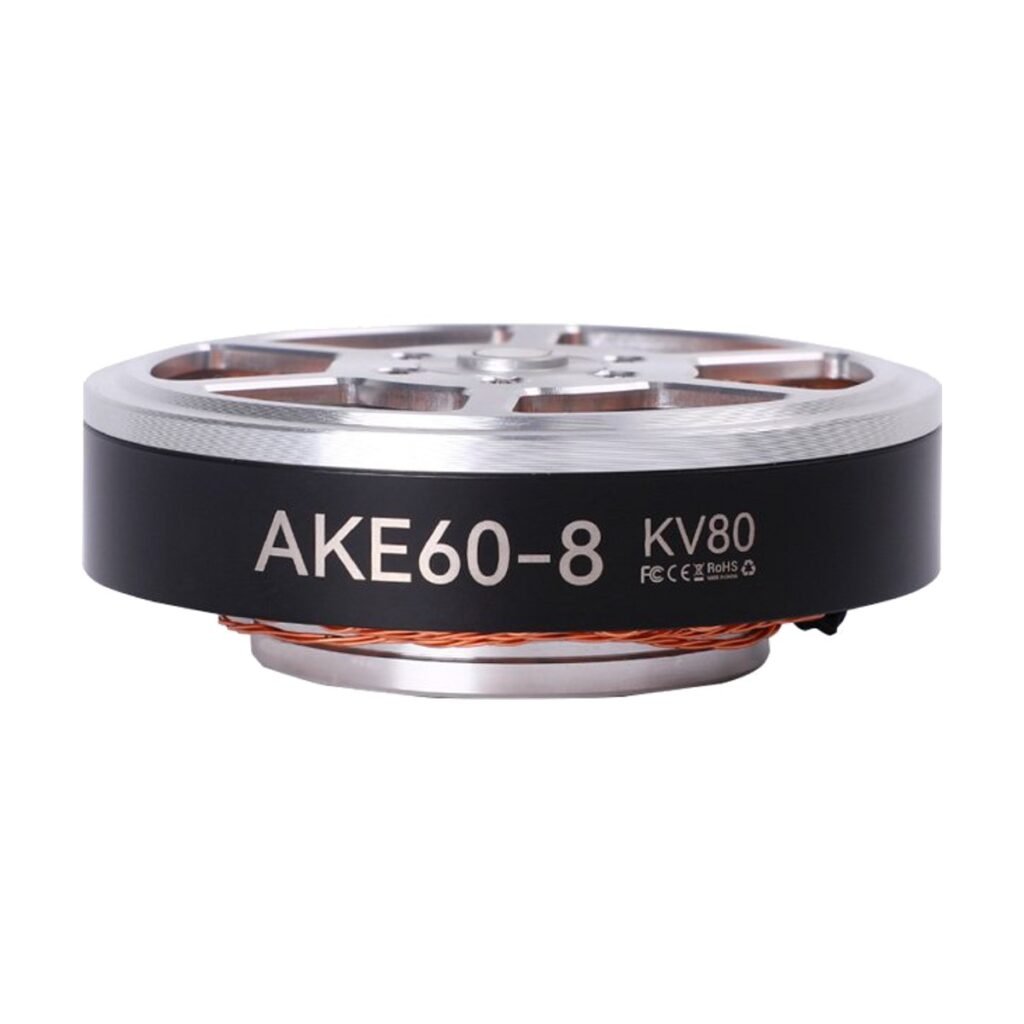
CubeMars AKE60-8 Joint Actuator
12.5 N·m5 N·m8:1$240.90 -
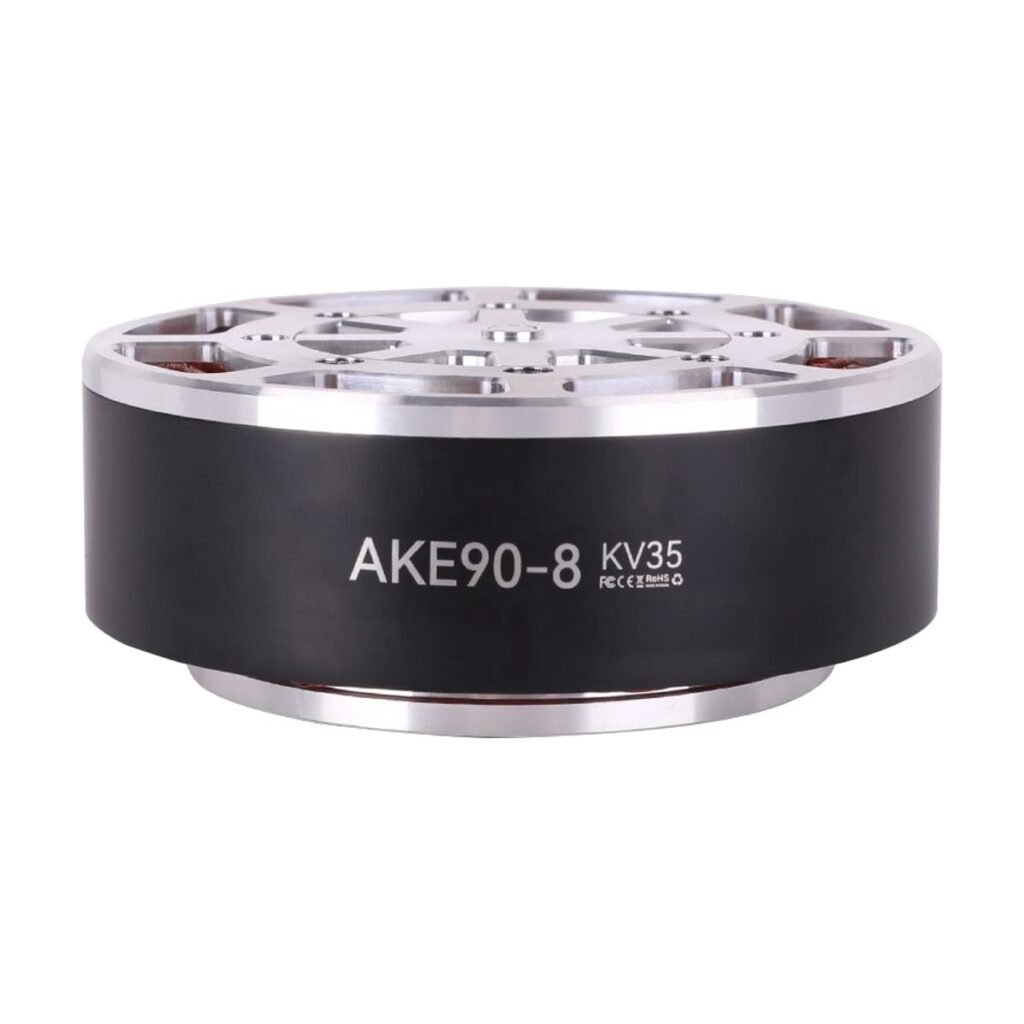
CubeMars AKE90-8 Joint Actuator
170 N·m55 N·m8:1$532.90 -
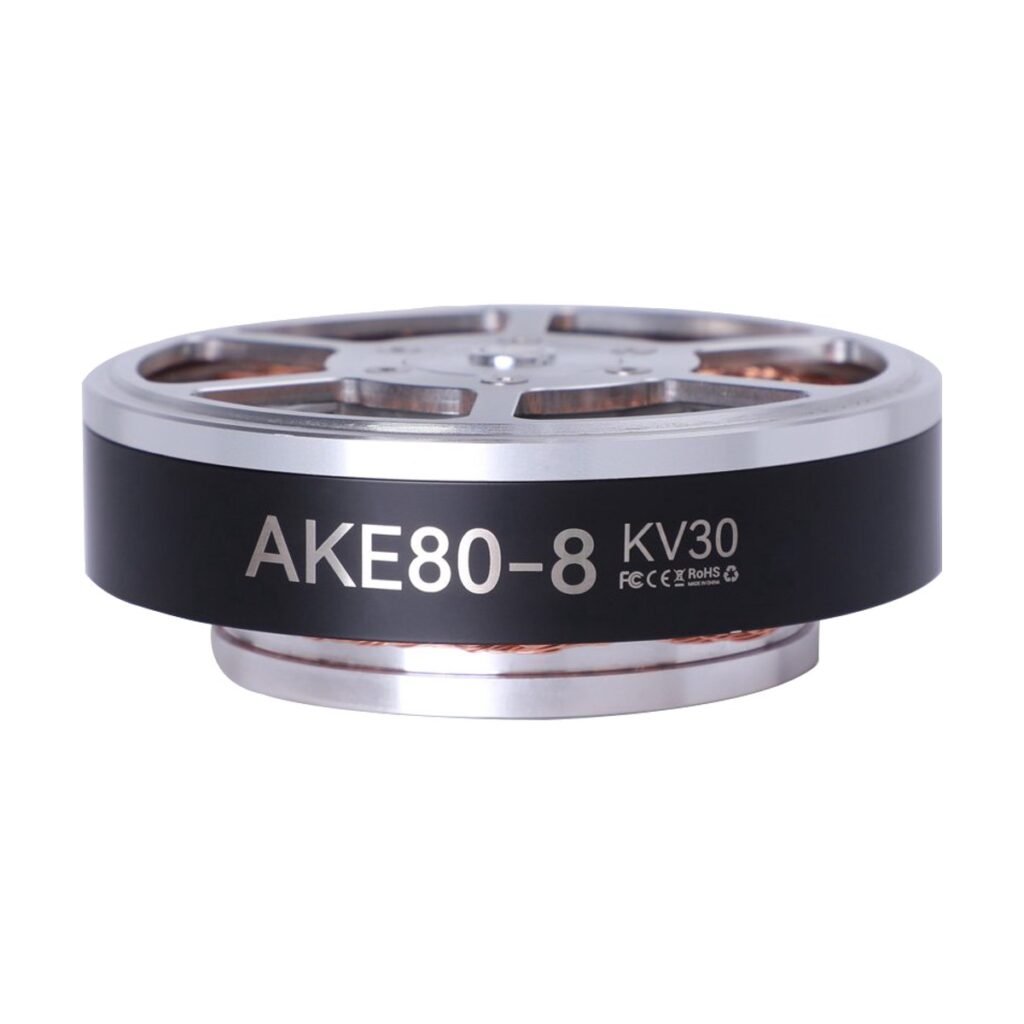
CubeMars AKE80-8 Joint Actuator
30 N·m12 N·m8:1$373.90 -
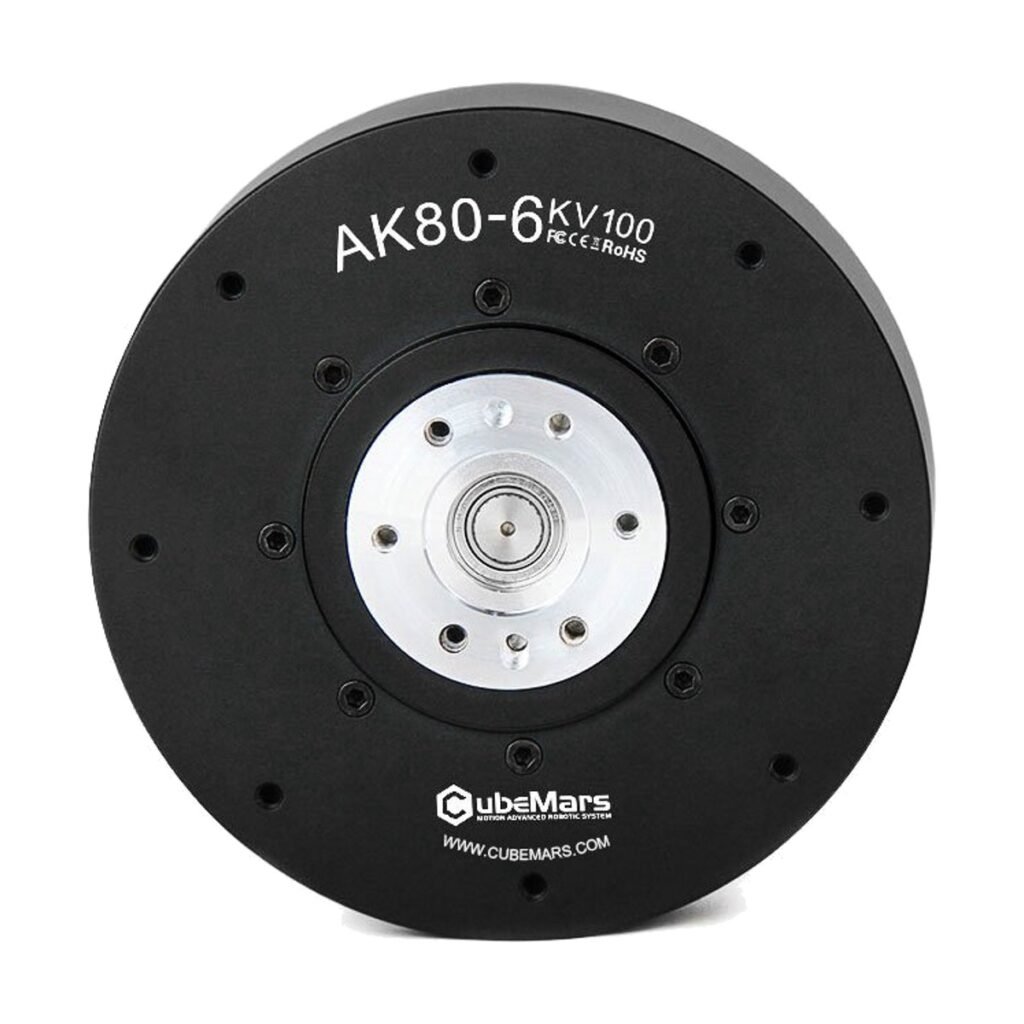
CubeMars AK80-6 Joint Actuator
12 N·m6 N·m6:1$516.90 -
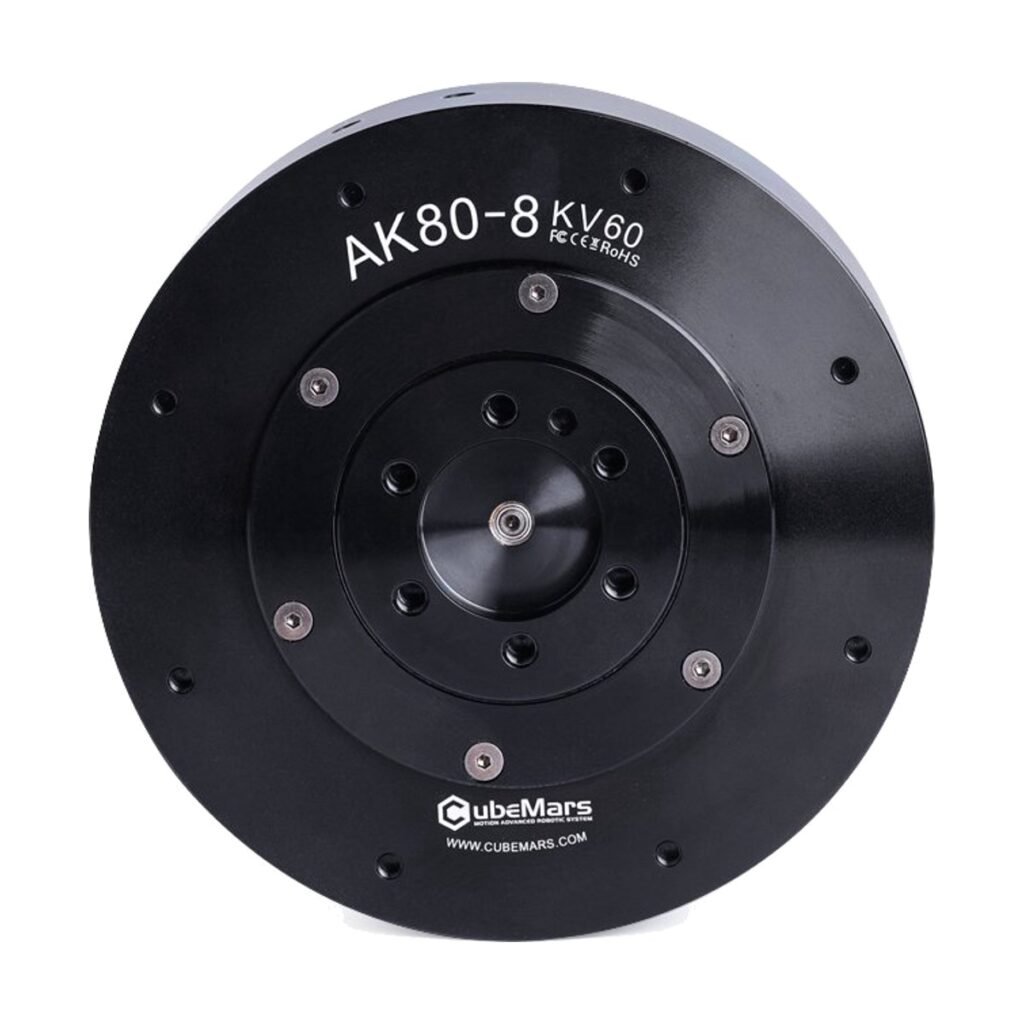
CubeMars AK80-8 Joint Actuator
25 N·m10 N·m8:1$516.90 -
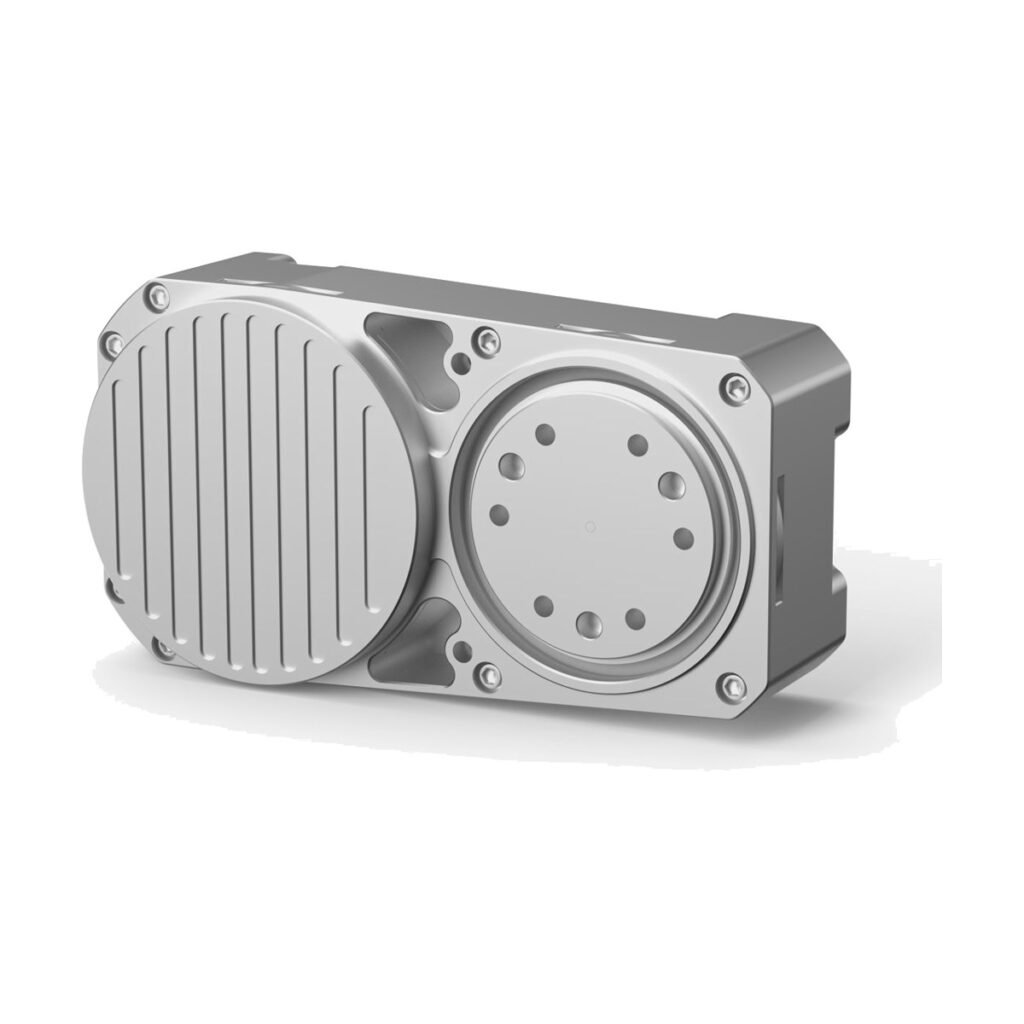
HighTorque HTPU-6035-04-CNE Joint Actuator
10 N·m35:1CAN$306.90