CubeMars·AK40-10 V3.0 KV170·RJT-002

CubeMars AK40-10 Joint Actuator

$149.90

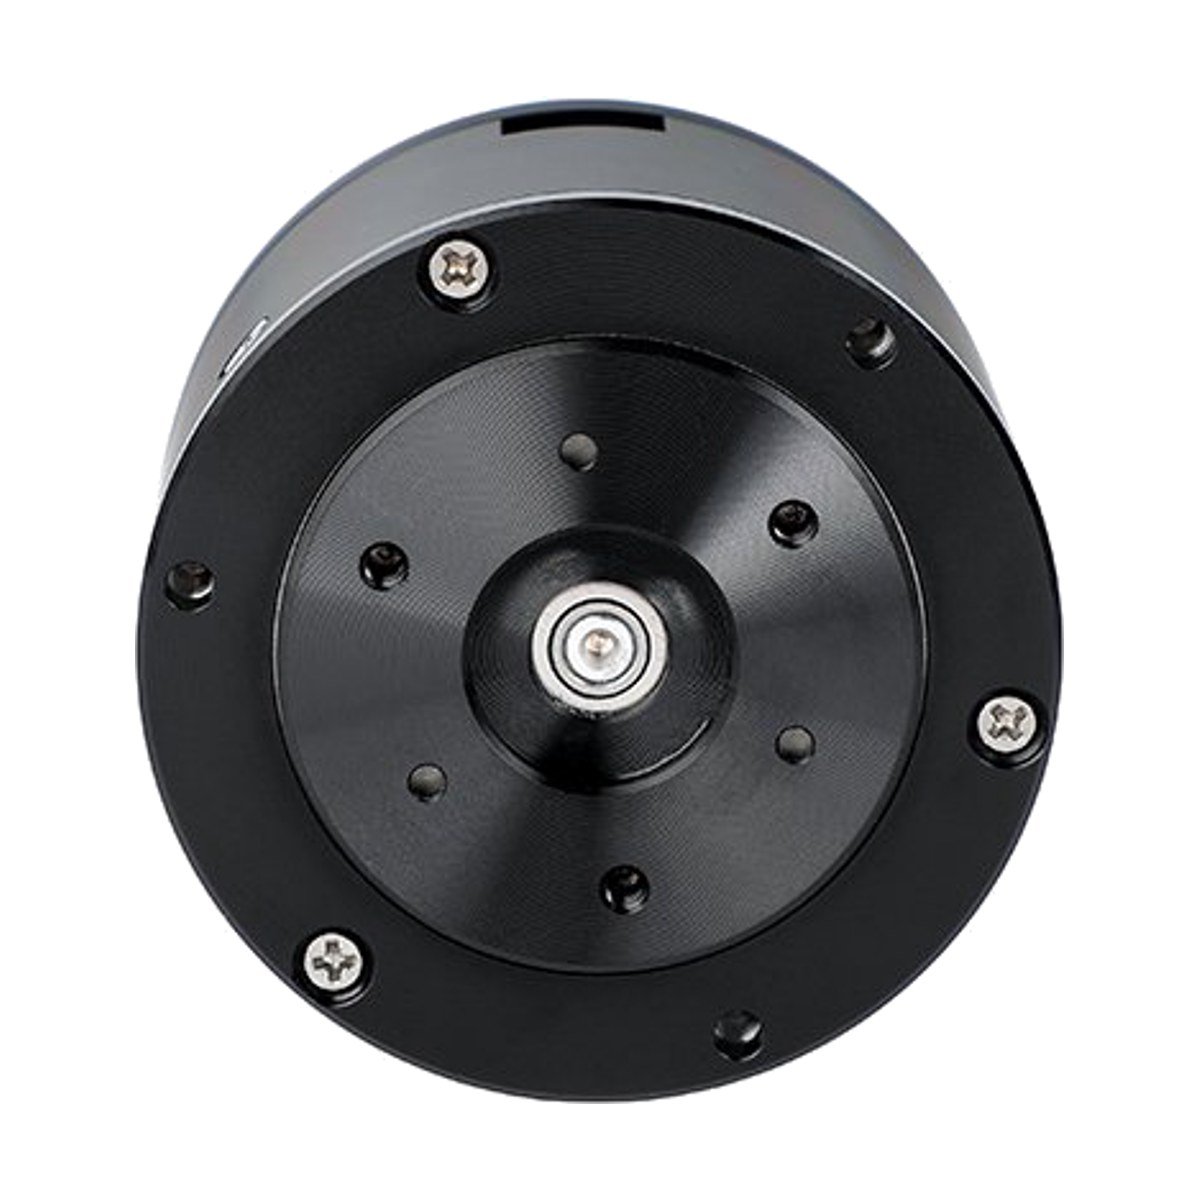
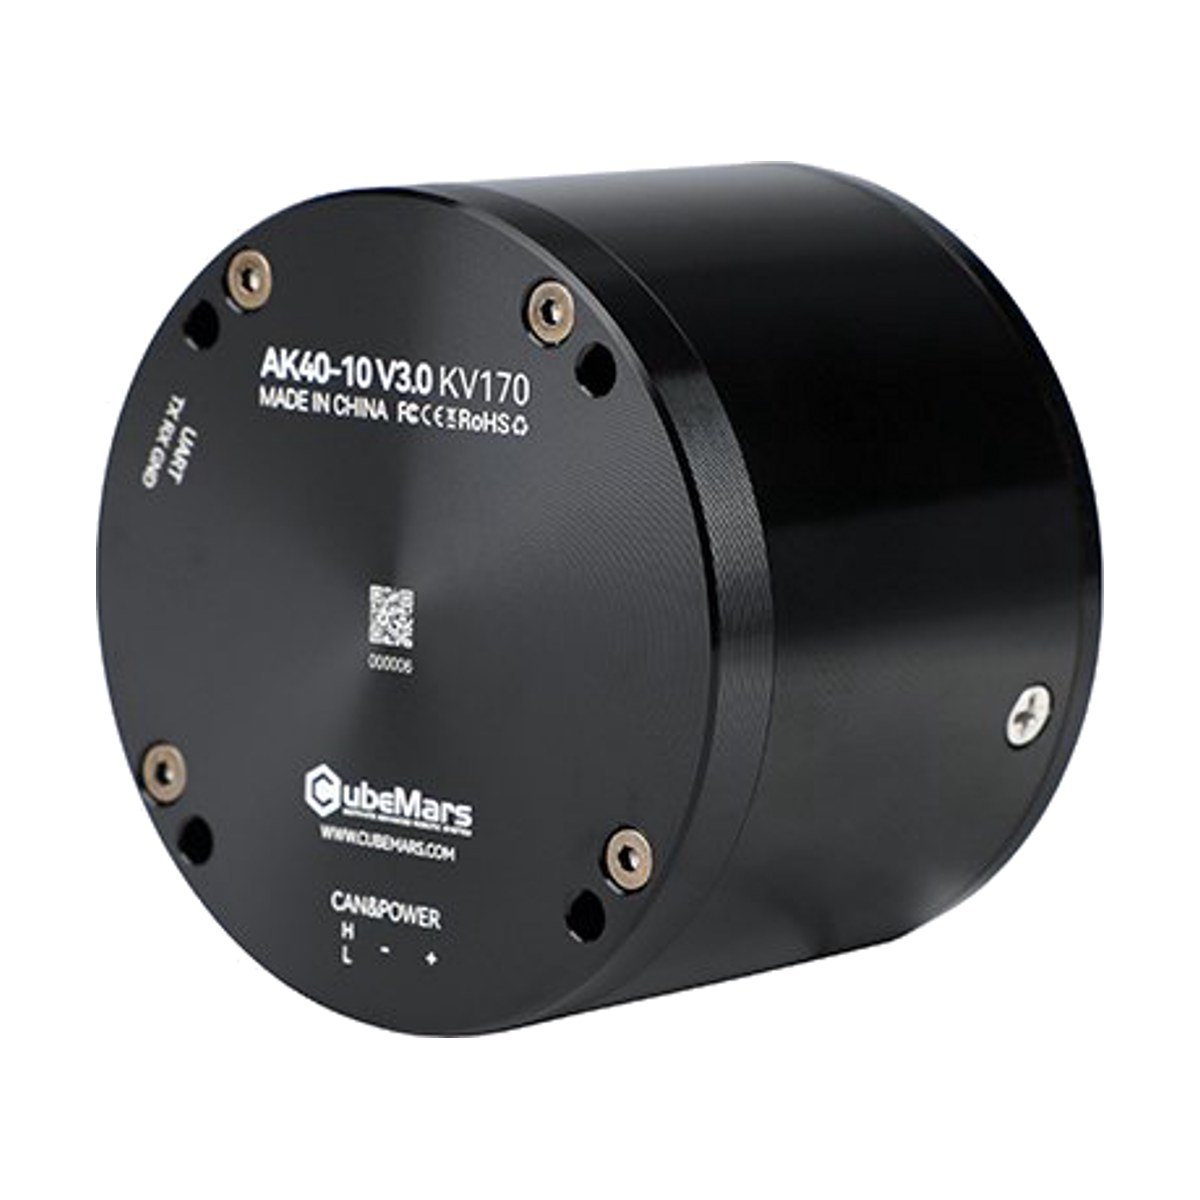
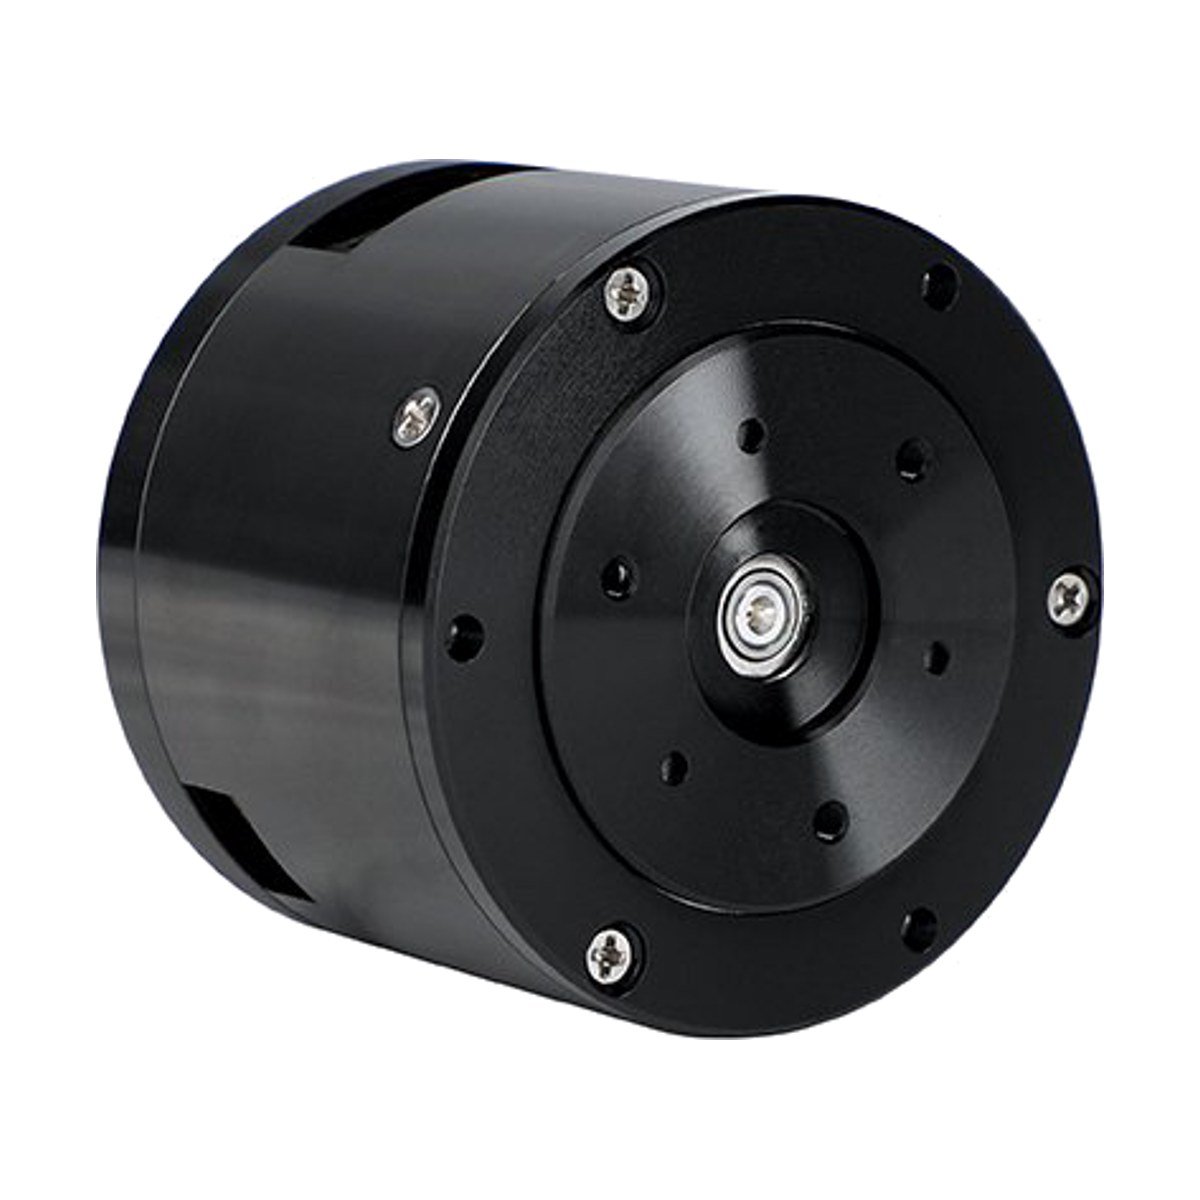
CubeMars AK40-10 V3.0 robotic actuator. Ultralight 190g module with 4.1Nm peak torque, 10:1 planetary reducer & dual encoders for compact humanoid robot joints.

Freight
Quoted after order
Minimum order
1 unit
In the box
Motor, gearing and driver included
Need volume pricing or a custom configuration? Request a quote →
4.1 N·m
Torque (peak / max)
1.3 N·m
Torque (rated)
10:1
Gear ratio
CAN
Communication

Specifications

Performance

Torque (peak / max)
4.1 N·m
Torque (rated)
1.3 N·m
Output speed
370 rpm
Motion
Continuous rotary

Mechanical

Gear ratio
10:1
Weight
0.19 kg

Electrical

KV
170 rpm/V

Interface

Communication
CAN

Specifications and photos are the maker's published data. Datasheets are available on request.

Typical applications

  • Legged and humanoid robots
  • Robot arms and cobots
  • Exoskeletons
  • Research and education platforms

Choosing the right one

  • Use peak torque for dynamic moves and rated torque for sustained load; keep continuous load under the rated value.
  • Low ratios (about 6:1 to 10:1, quasi-direct drive) are backdrivable and suit legged robots; high ratios (30:1 and up) suit arms that need stiffness.
  • Check bus voltage (24 V or 48 V) and communication (CAN or CAN FD, EtherCAT, RS485) against your controller.
  • A dual encoder reports absolute output position at power-up, so the joint needs no homing.
  • Compare torque density (N·m per kg) when weight matters.

About this product

CubeMars AK40-10 V3.0 robotic actuator. Ultralight 190g module with 4.1Nm peak torque, 10:1 planetary reducer & dual encoders for compact humanoid robot joints.

  • Series: AK series
  • Factory model: AK40-10 V3.0 KV170
  • Made by CubeMars

Similar torque

Closest matches in this category, from any supplier.
More from CubeMars

Visit storefront →