Quasi-Direct-Drive Joints
Low-ratio (up to 12:1) planetary joint modules. Backdrivable and fast, for legged robots, humanoid legs and exoskeletons.
-
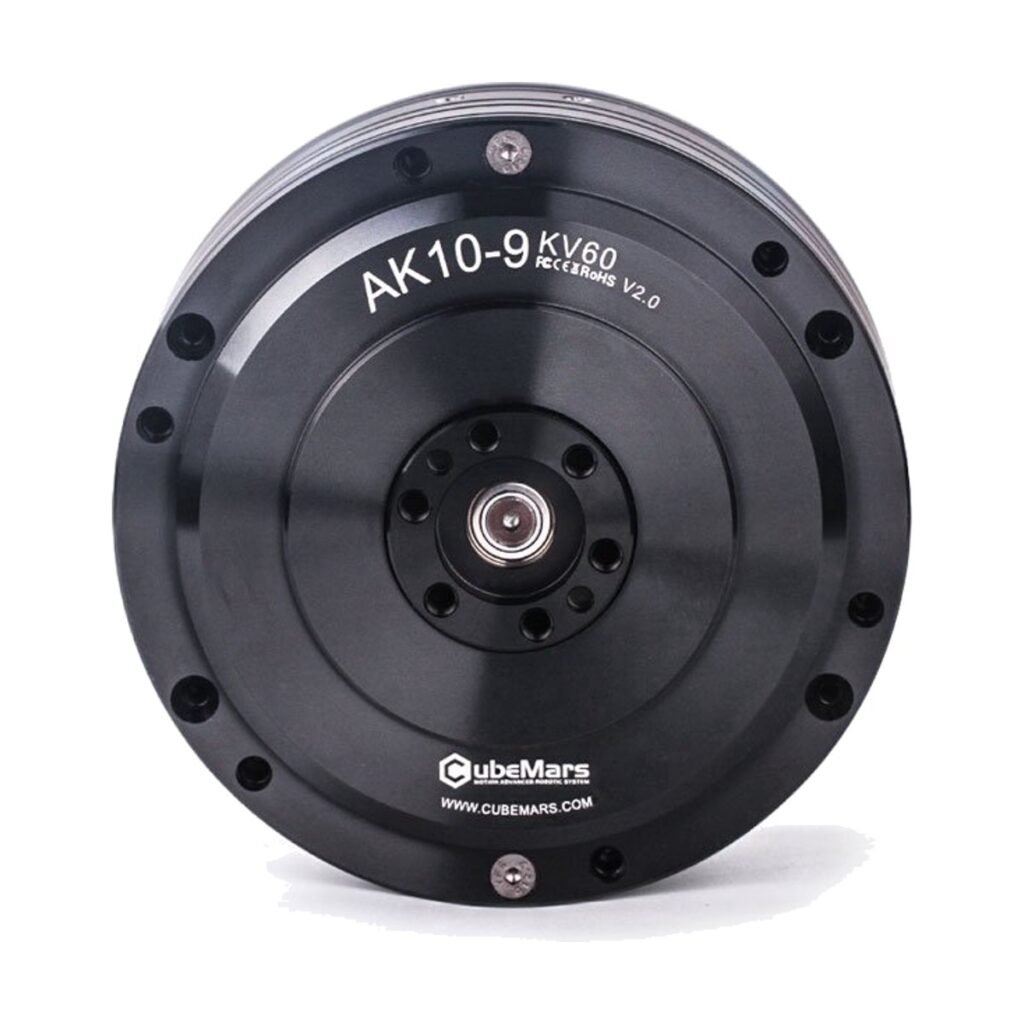
CubeMars AK10-9 Joint Actuator (V2.0 KV60)
48 N·m18 N·m9:1$768.90 -
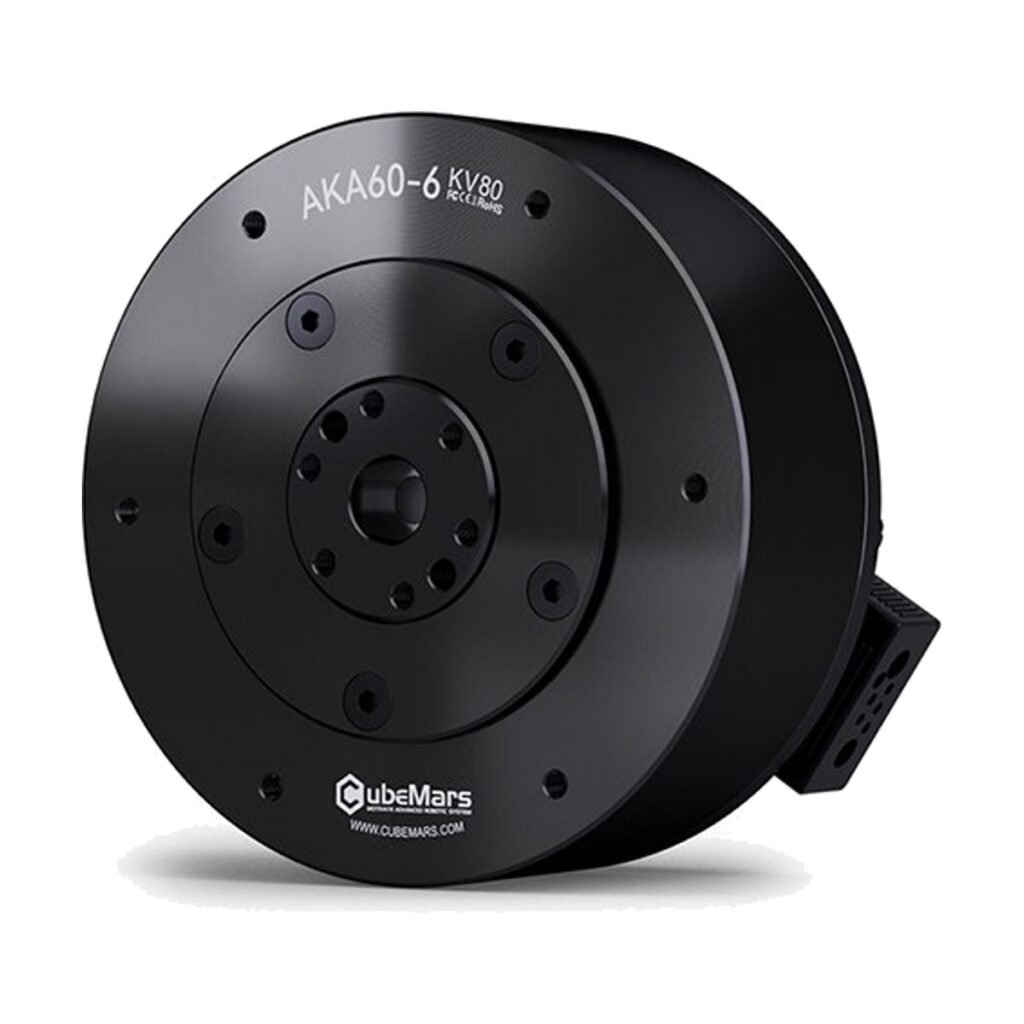
CubeMars AKA60-6 Joint Actuator
9 N·m3 N·m6:1$328.90 -
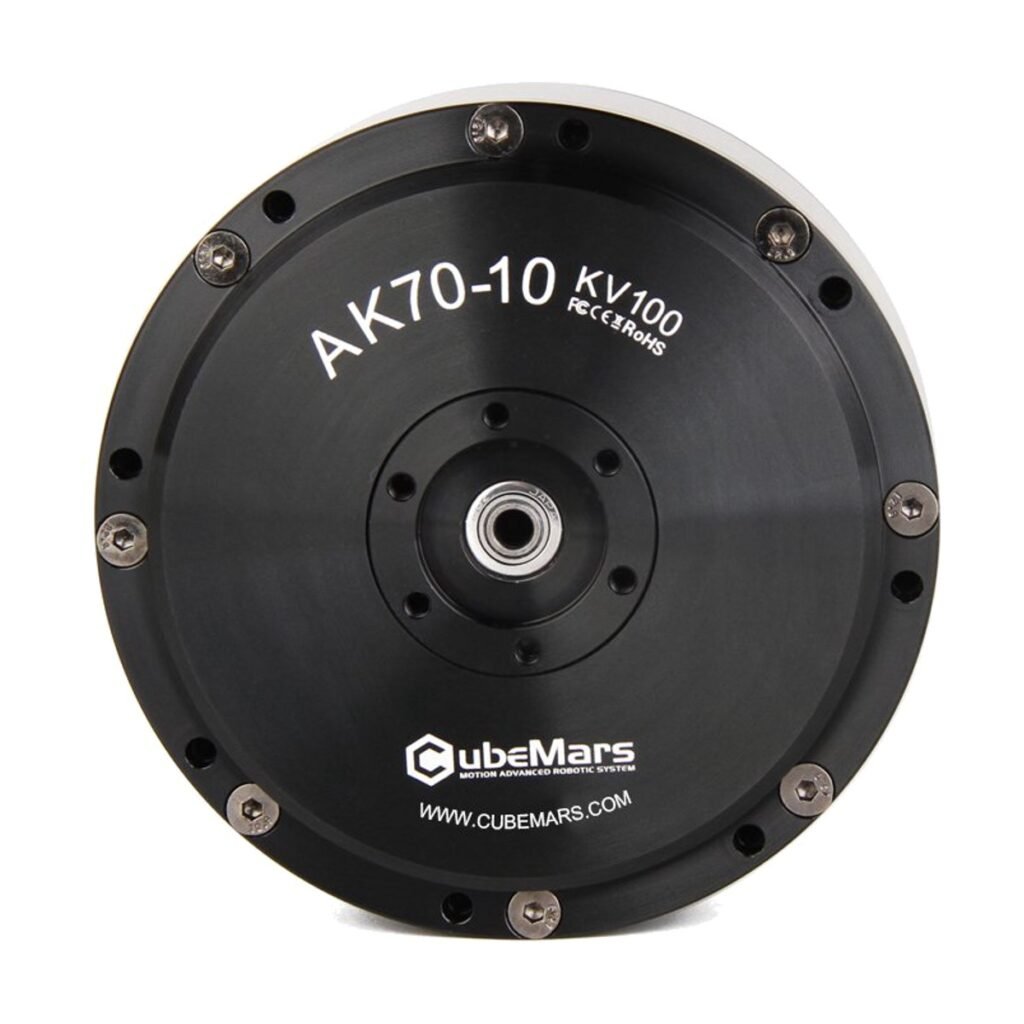
CubeMars AK70-10 Joint Actuator
24.8 N·m8.3 N·m10:1$438.90 -
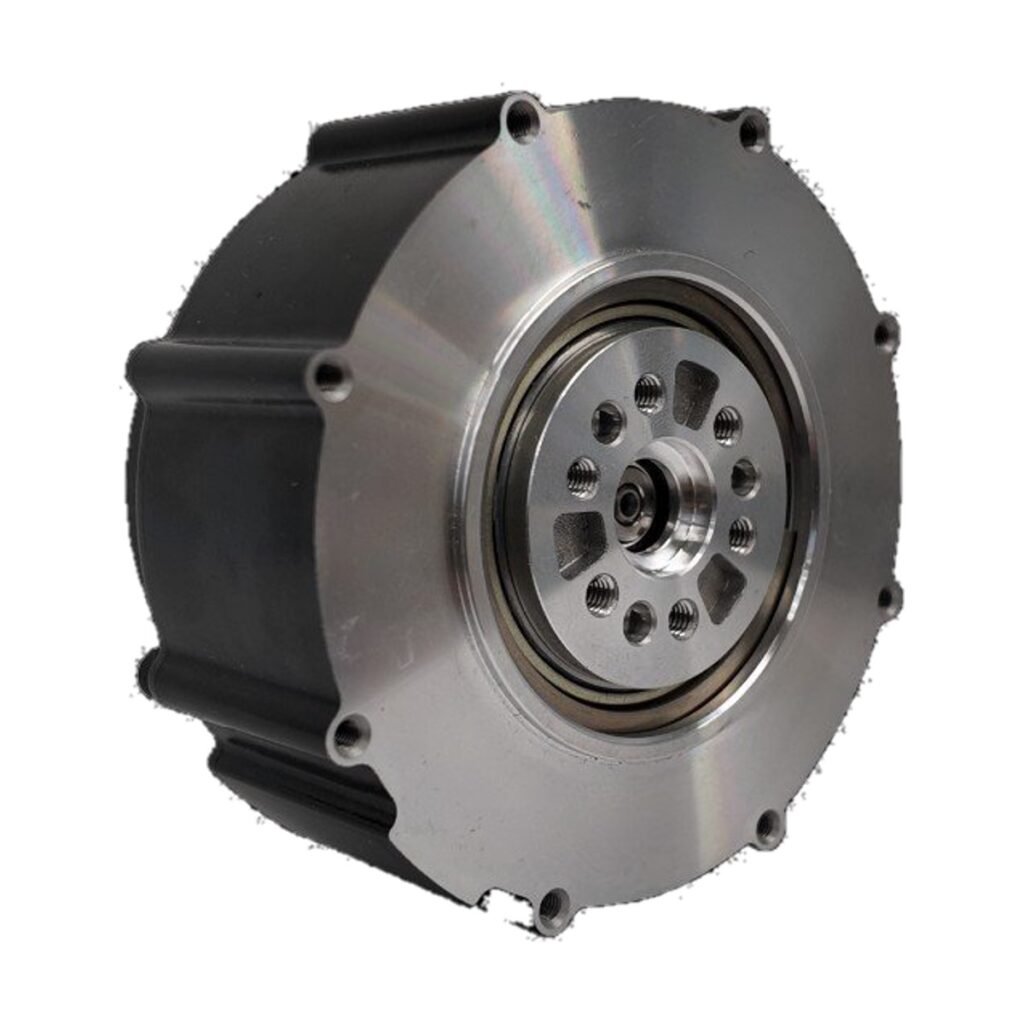
RobStride 06 Joint Actuator
6 N·m1.8 N·m9:1$231.90 -
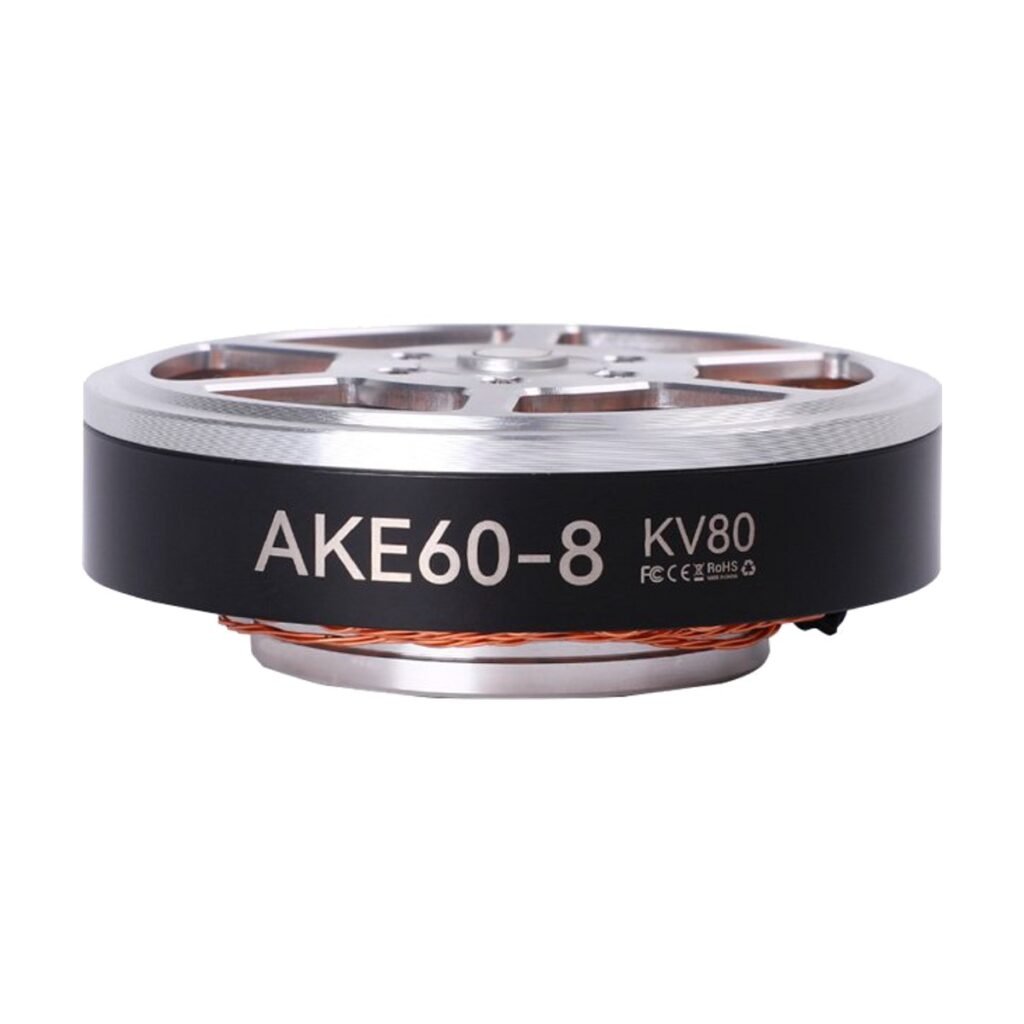
CubeMars AKE60-8 Joint Actuator
12.5 N·m5 N·m8:1$240.90 -
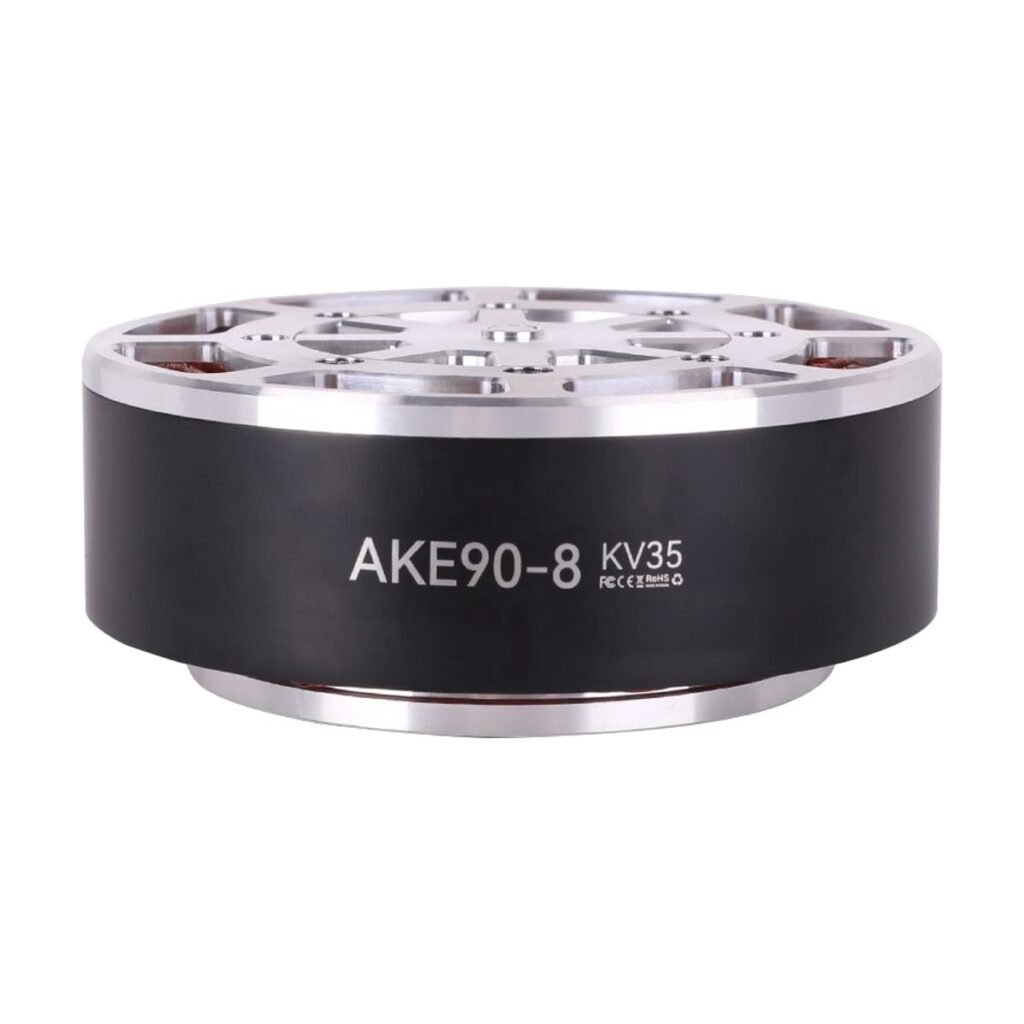
CubeMars AKE90-8 Joint Actuator
170 N·m55 N·m8:1$532.90 -
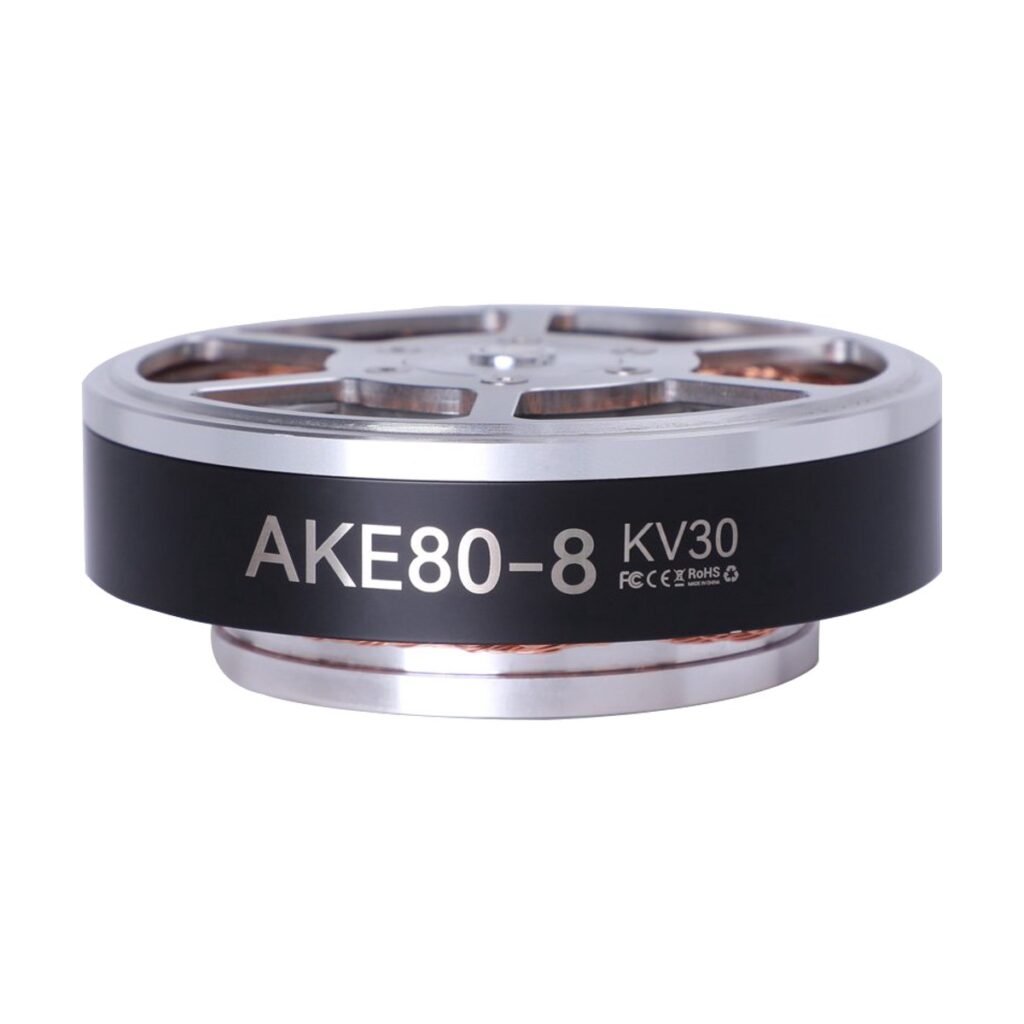
CubeMars AKE80-8 Joint Actuator
30 N·m12 N·m8:1$373.90 -
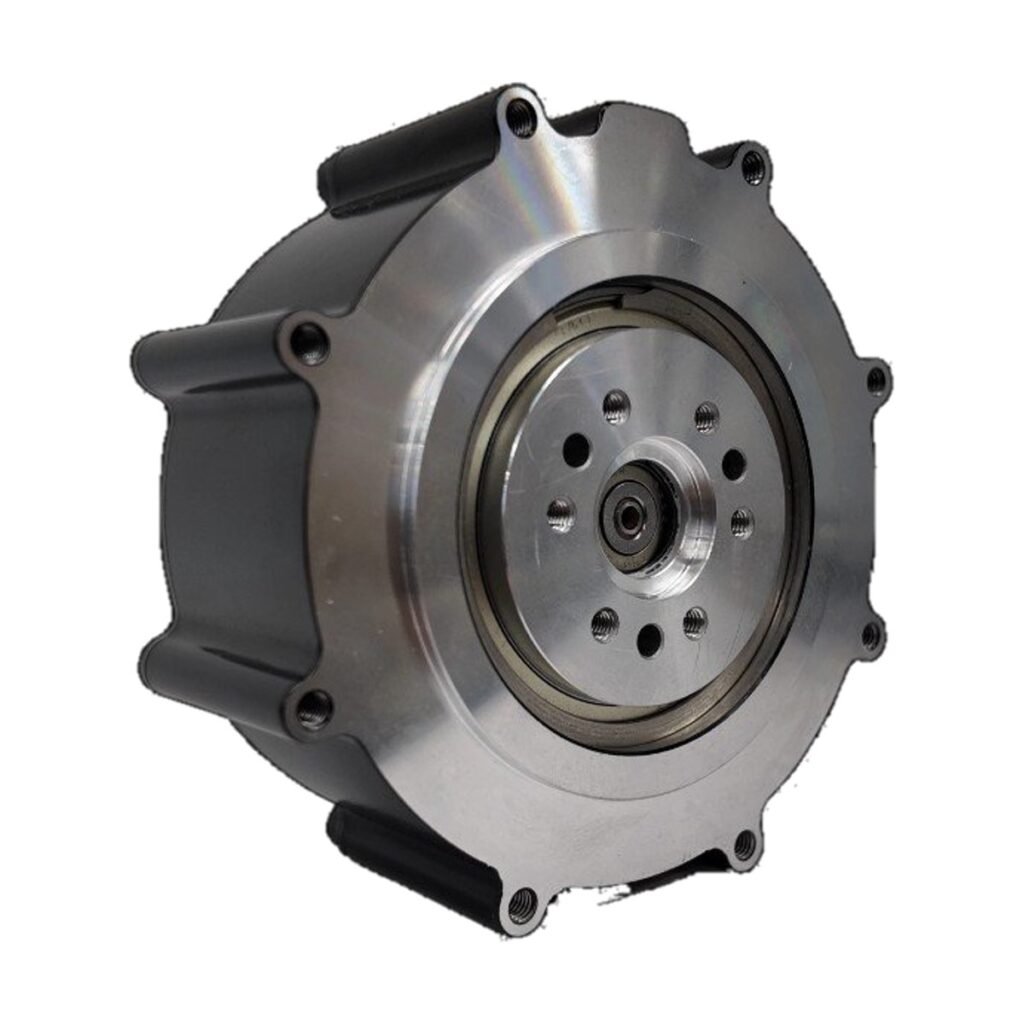
RobStride 03 Joint Actuator
60 N·m20 N·m9:1$247.90 -
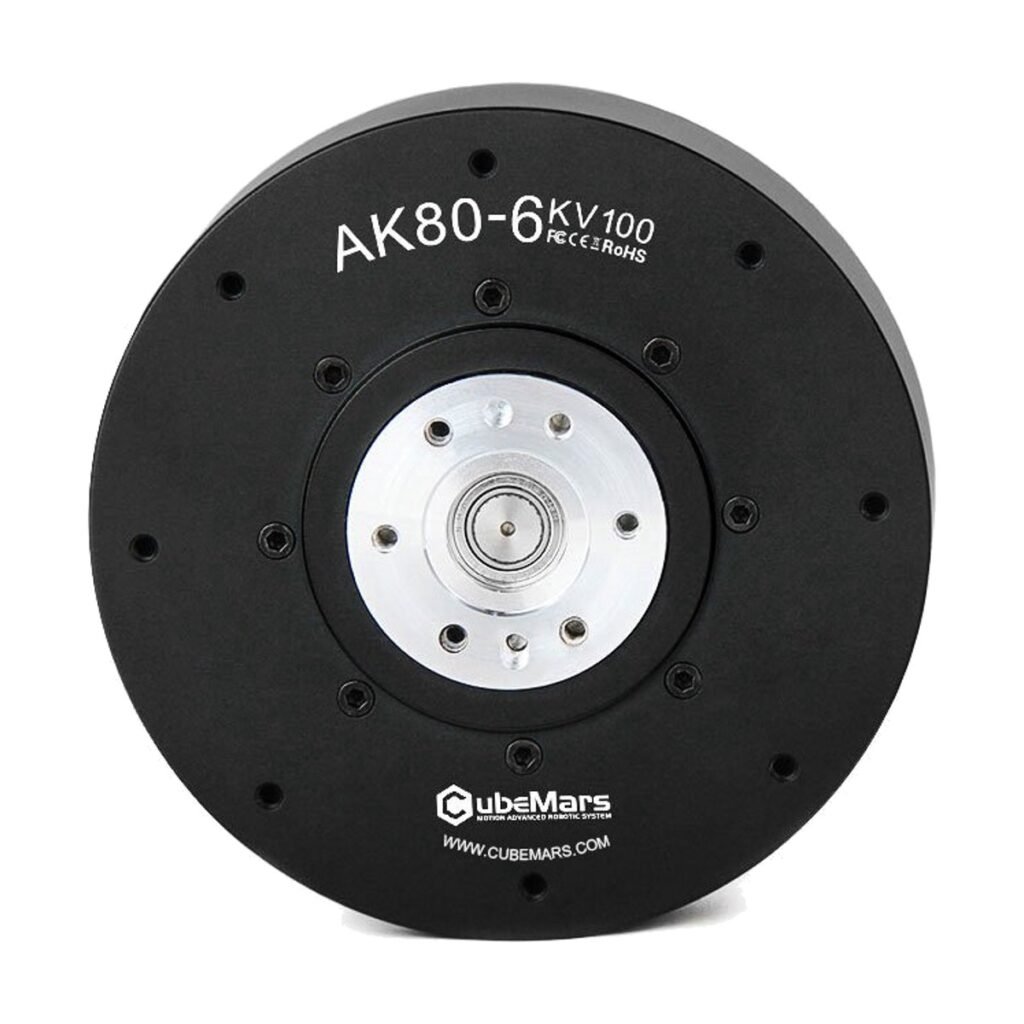
CubeMars AK80-6 Joint Actuator
12 N·m6 N·m6:1$516.90 -
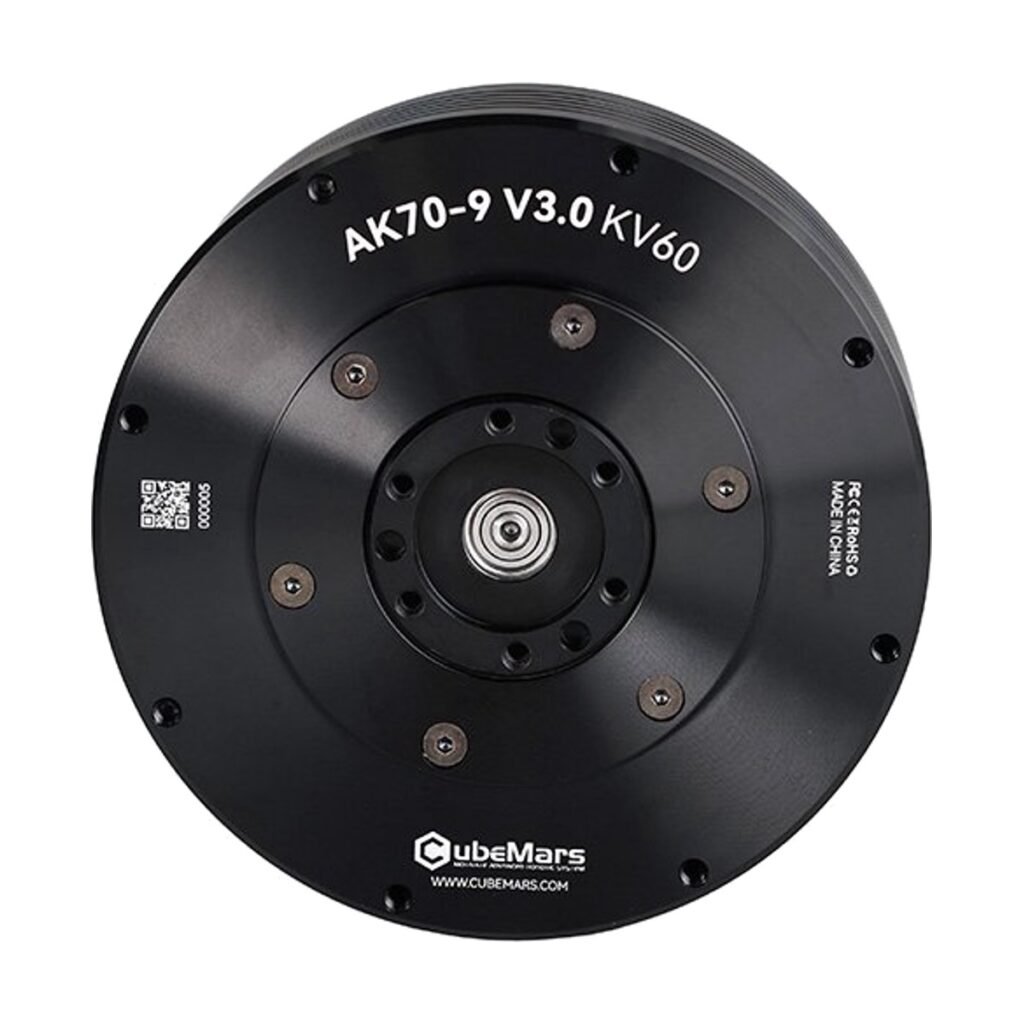
CubeMars AK70-9 Joint Actuator
29.2 N·m8.5 N·m9:1$438.90 -
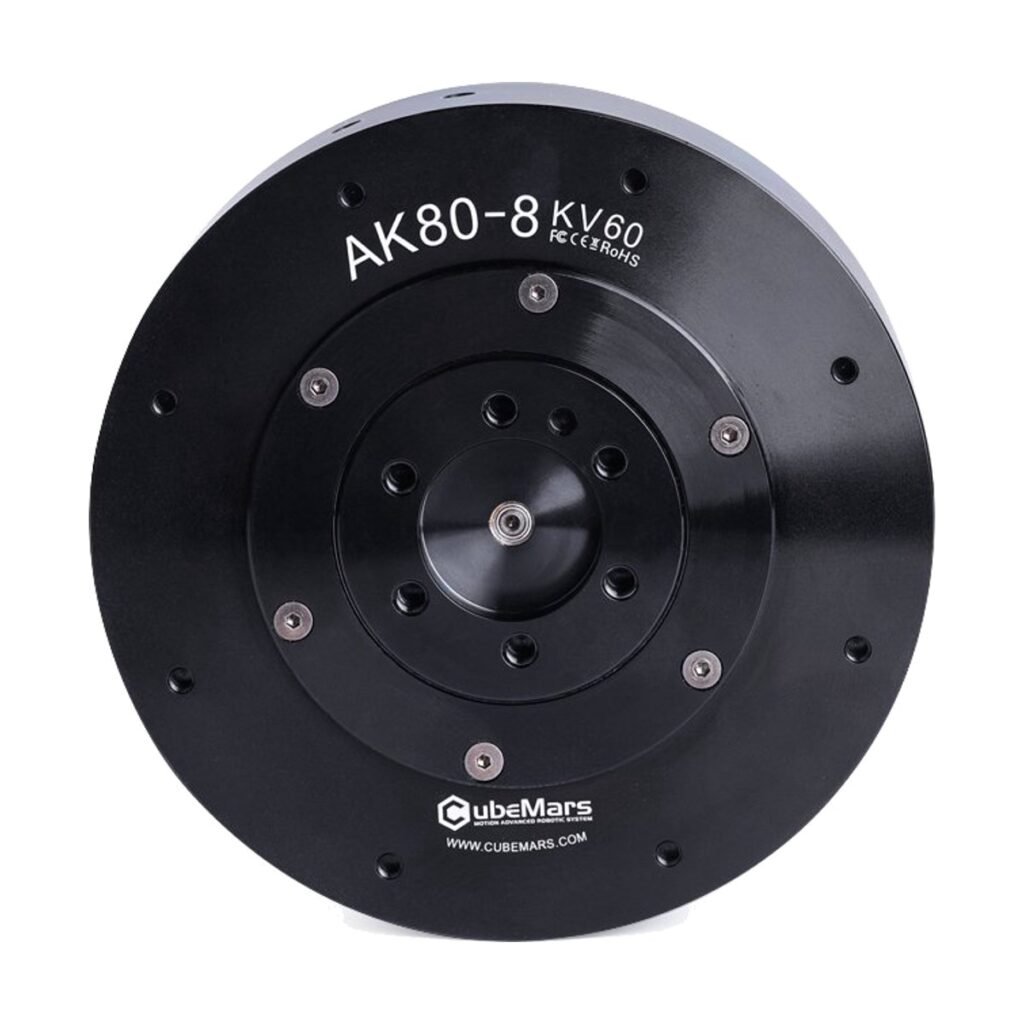
CubeMars AK80-8 Joint Actuator
25 N·m10 N·m8:1$516.90 -
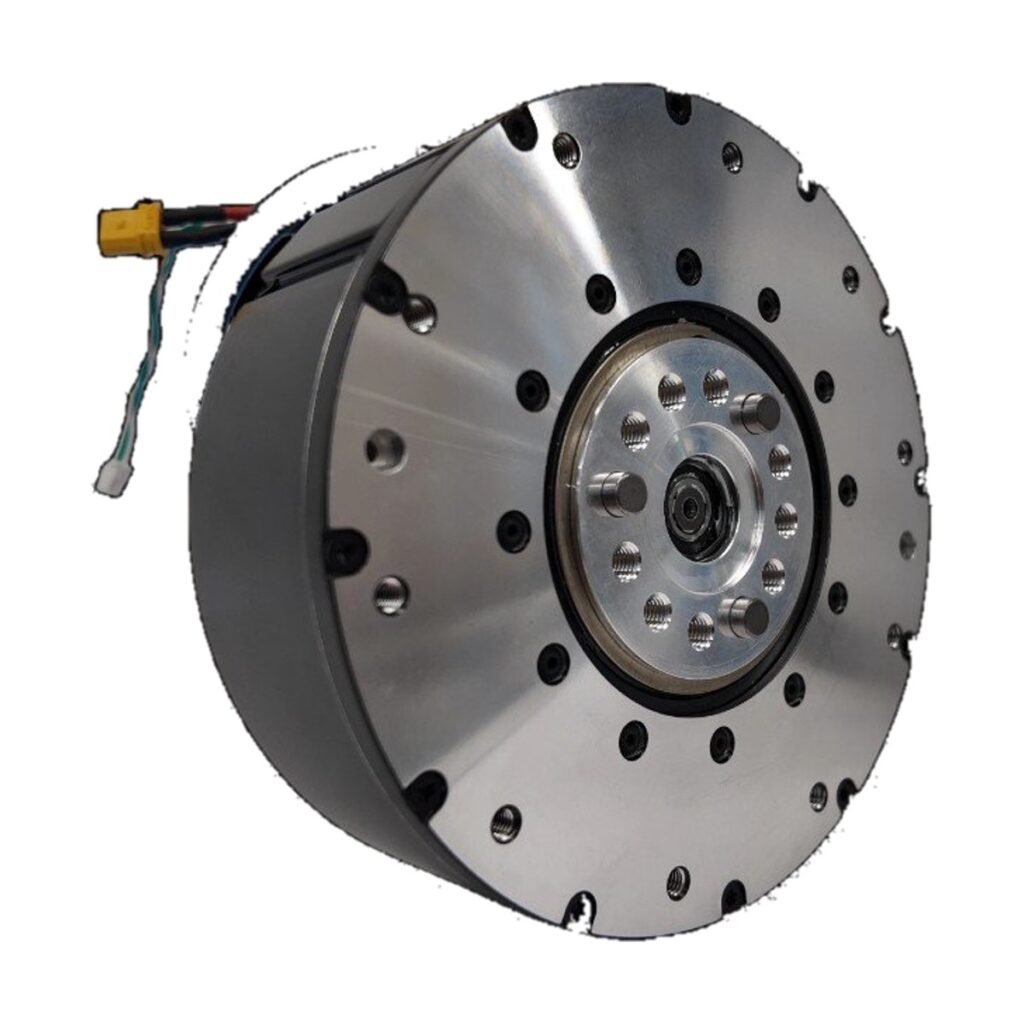
RobStride 04 Joint Actuator
120 N·m40 N·m9:1$280.90 -
CubeMars AK40-10 Joint Actuator
4.1 N·m1.3 N·m10:1$149.90 -
CubeMars AK45-10 Joint Actuator
7 N·m2.5 N·m10:1$171.90 -
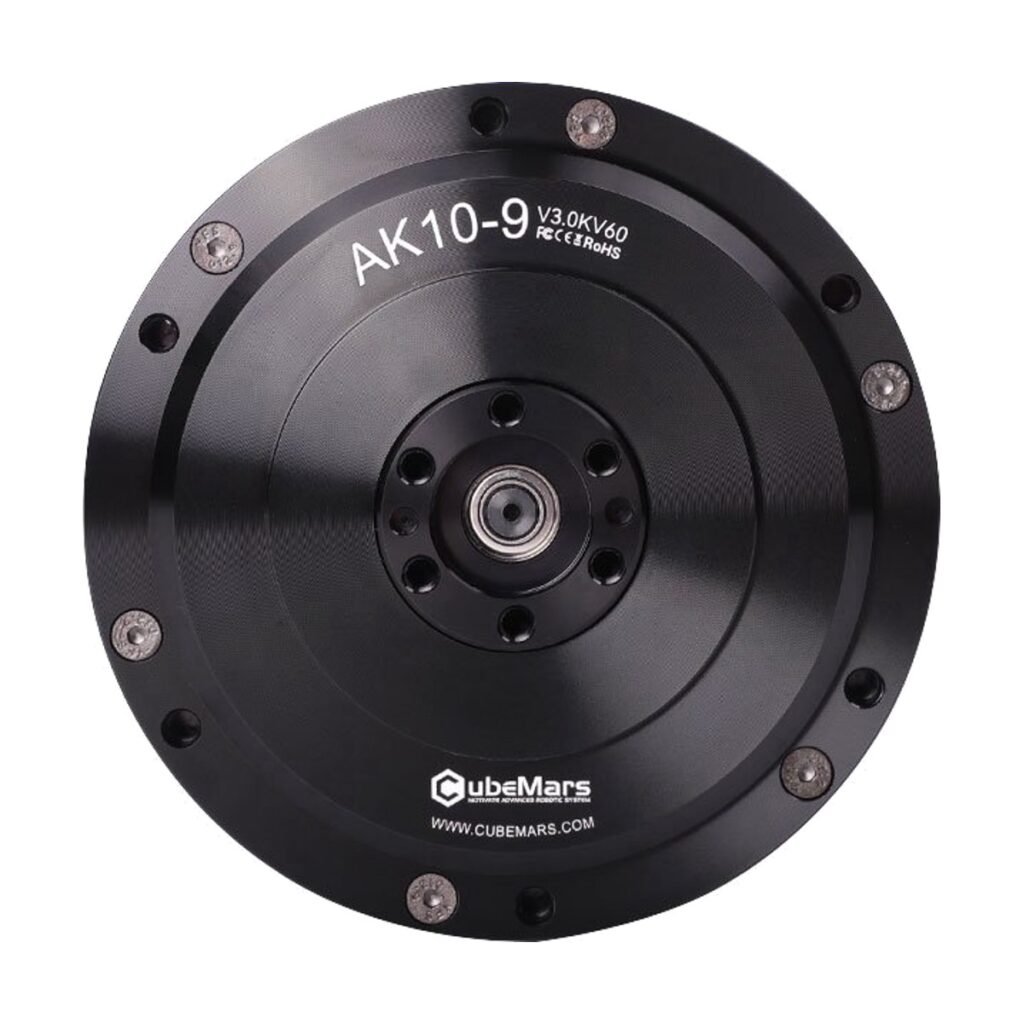
CubeMars AK10-9 Joint Actuator (V3.0 KV60)
53 N·m18 N·m9:1$768.90 -
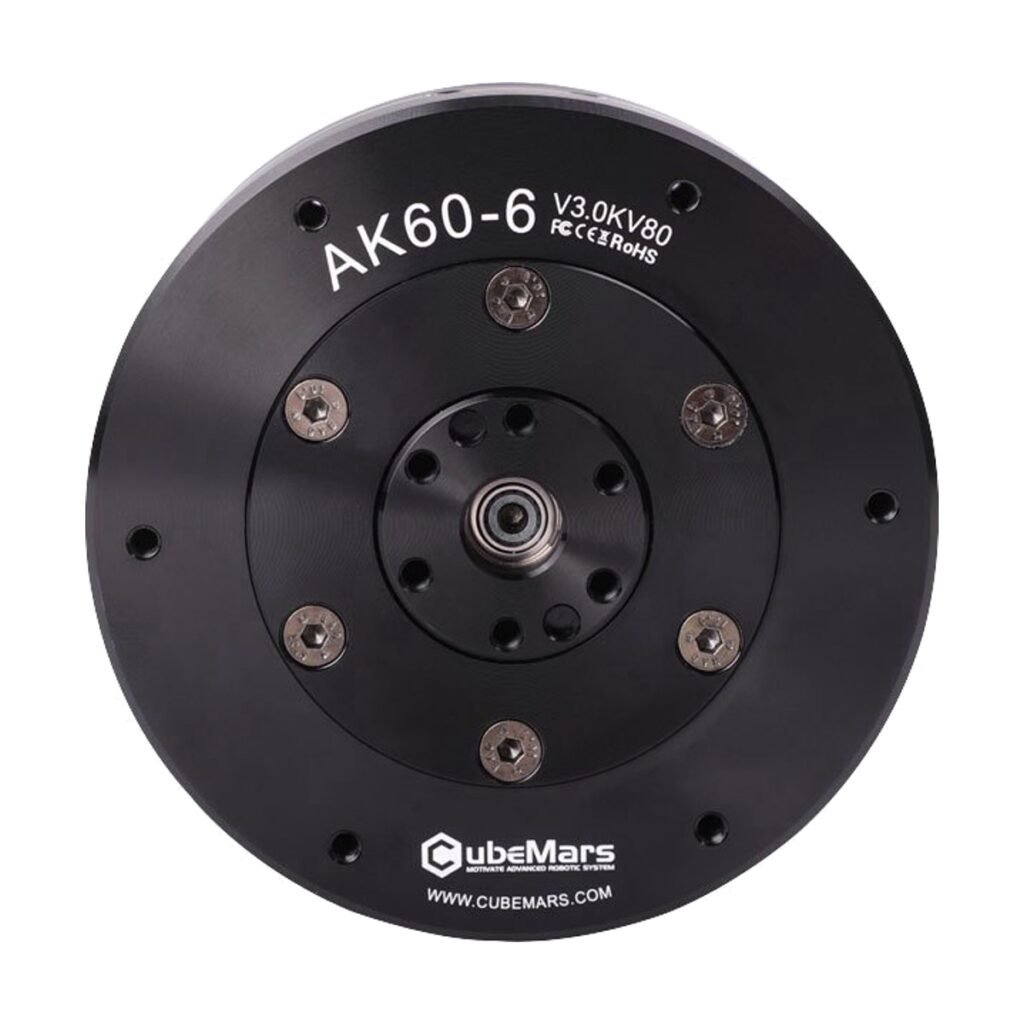
CubeMars AK60-6 Joint Actuator (V3.0 KV80)
9 N·m3 N·m6:1$252.90 -
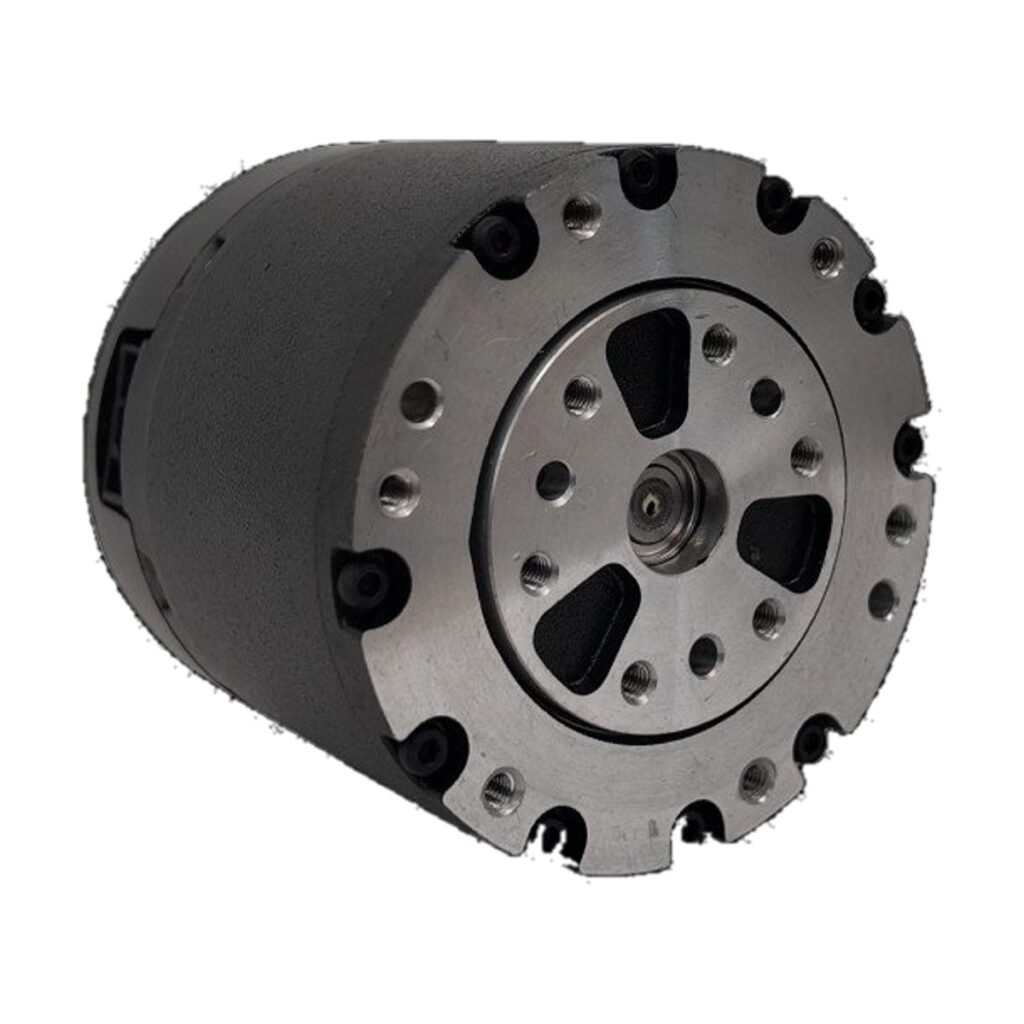
RobStride 00 Joint Actuator
10:1CAN$137.90 -
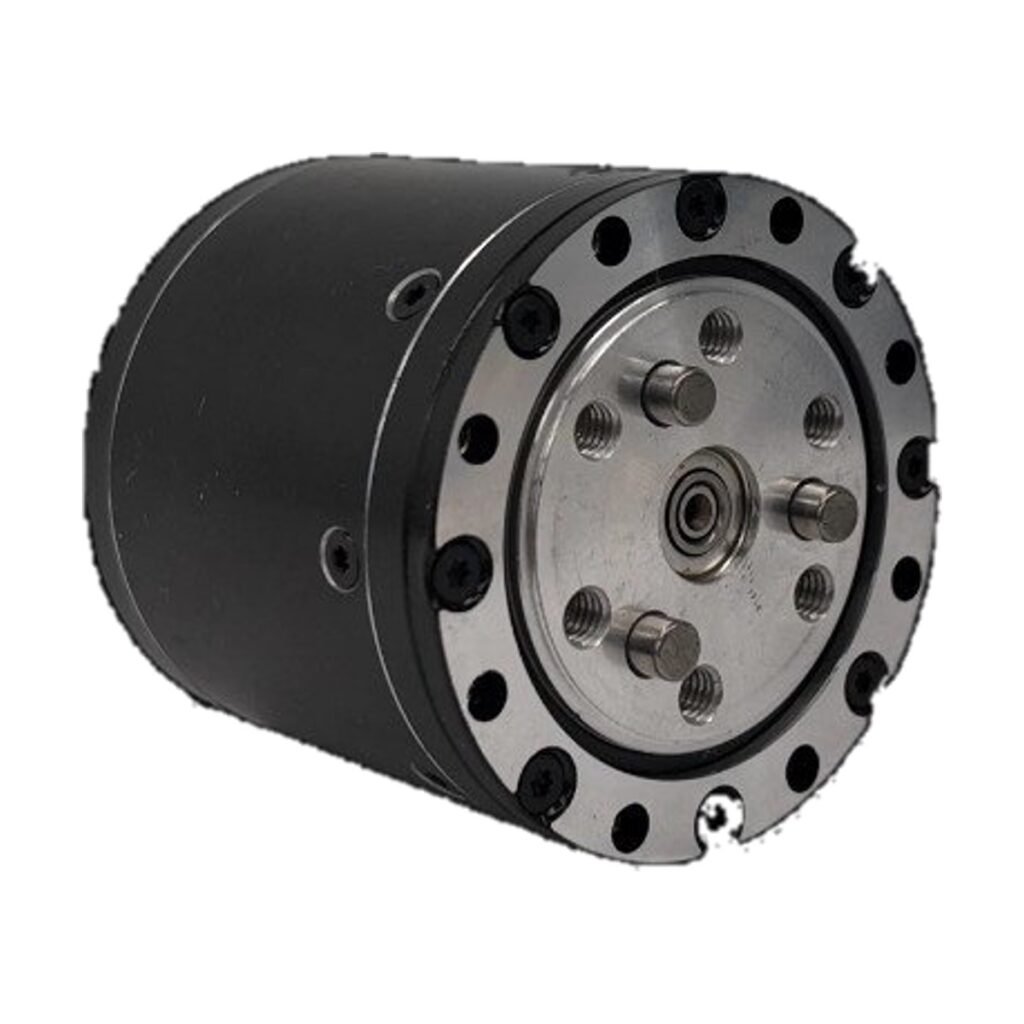
RobStride 05 Joint Actuator
7.75:1CAN$121.90